Publications
2026
-
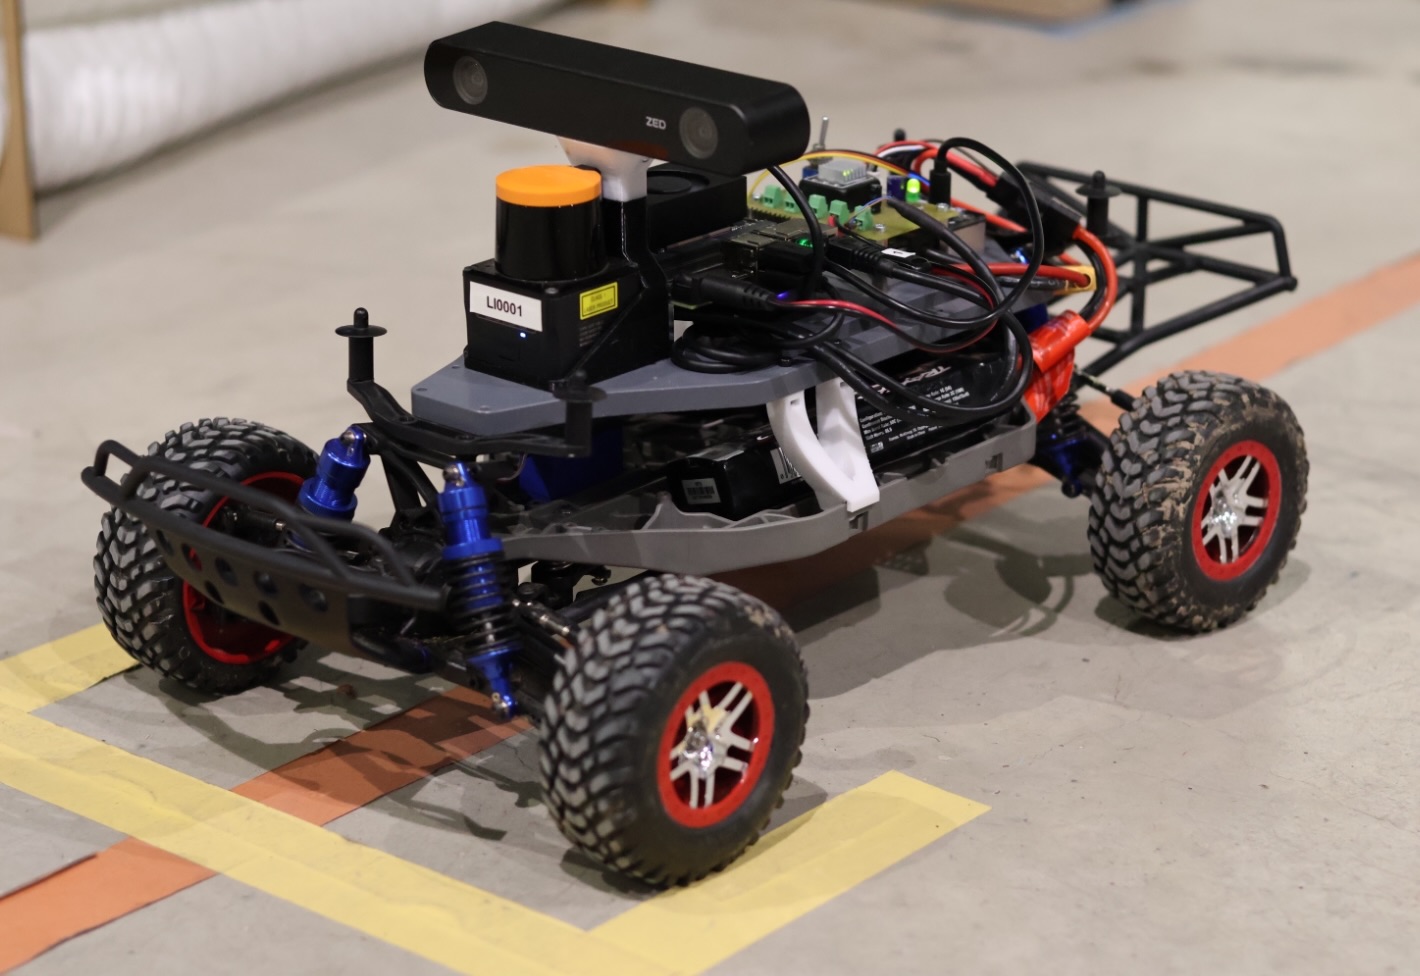
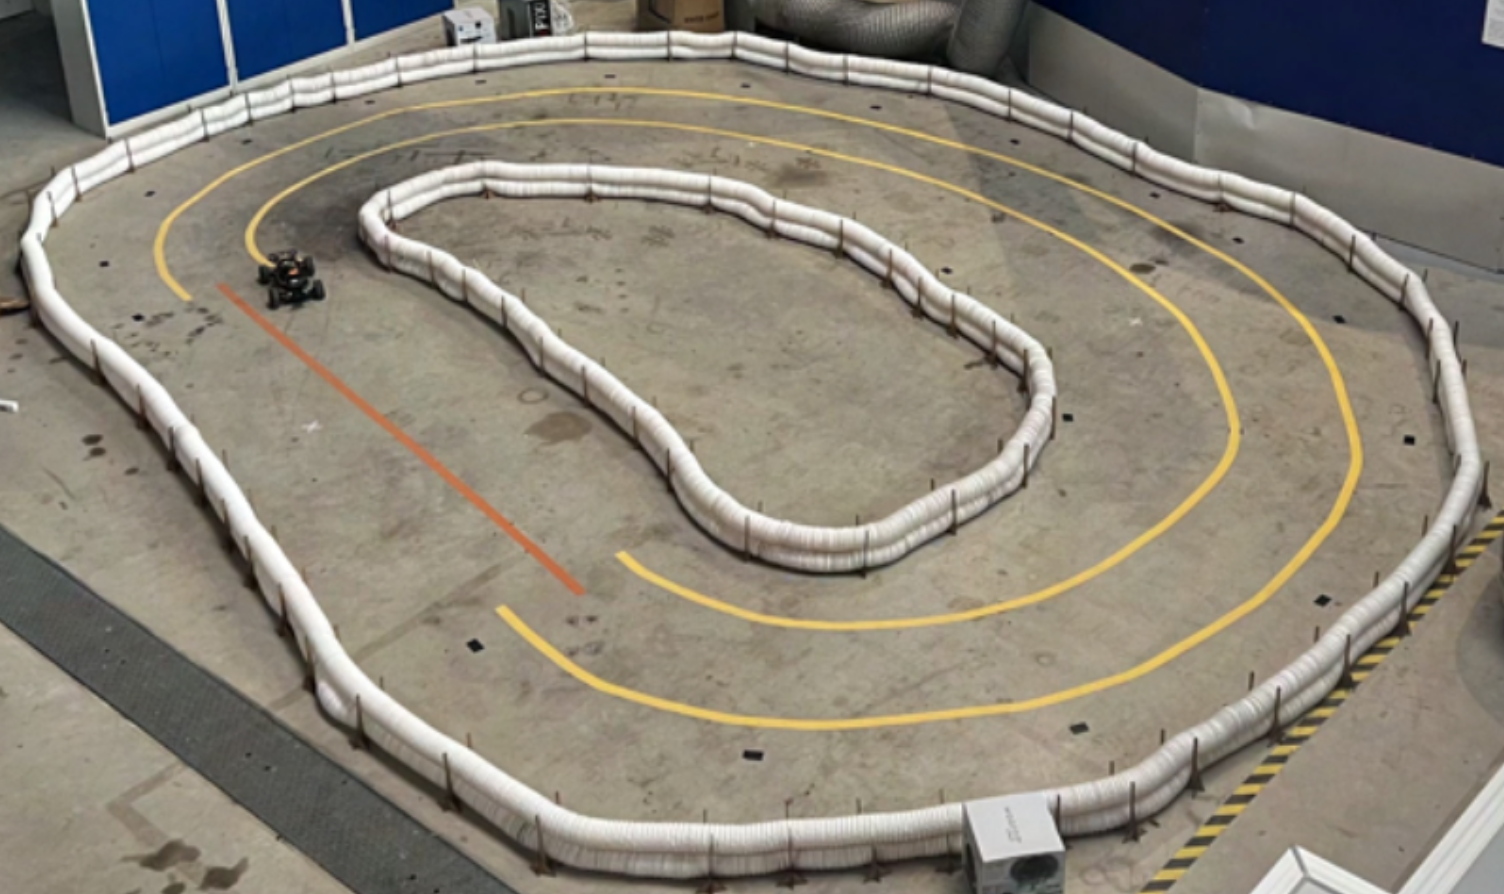 Trajectory Planning and Control Near the Limits: An Open Experimental Benchmark on the RoboRacer PlatformIn 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026Accepted
-
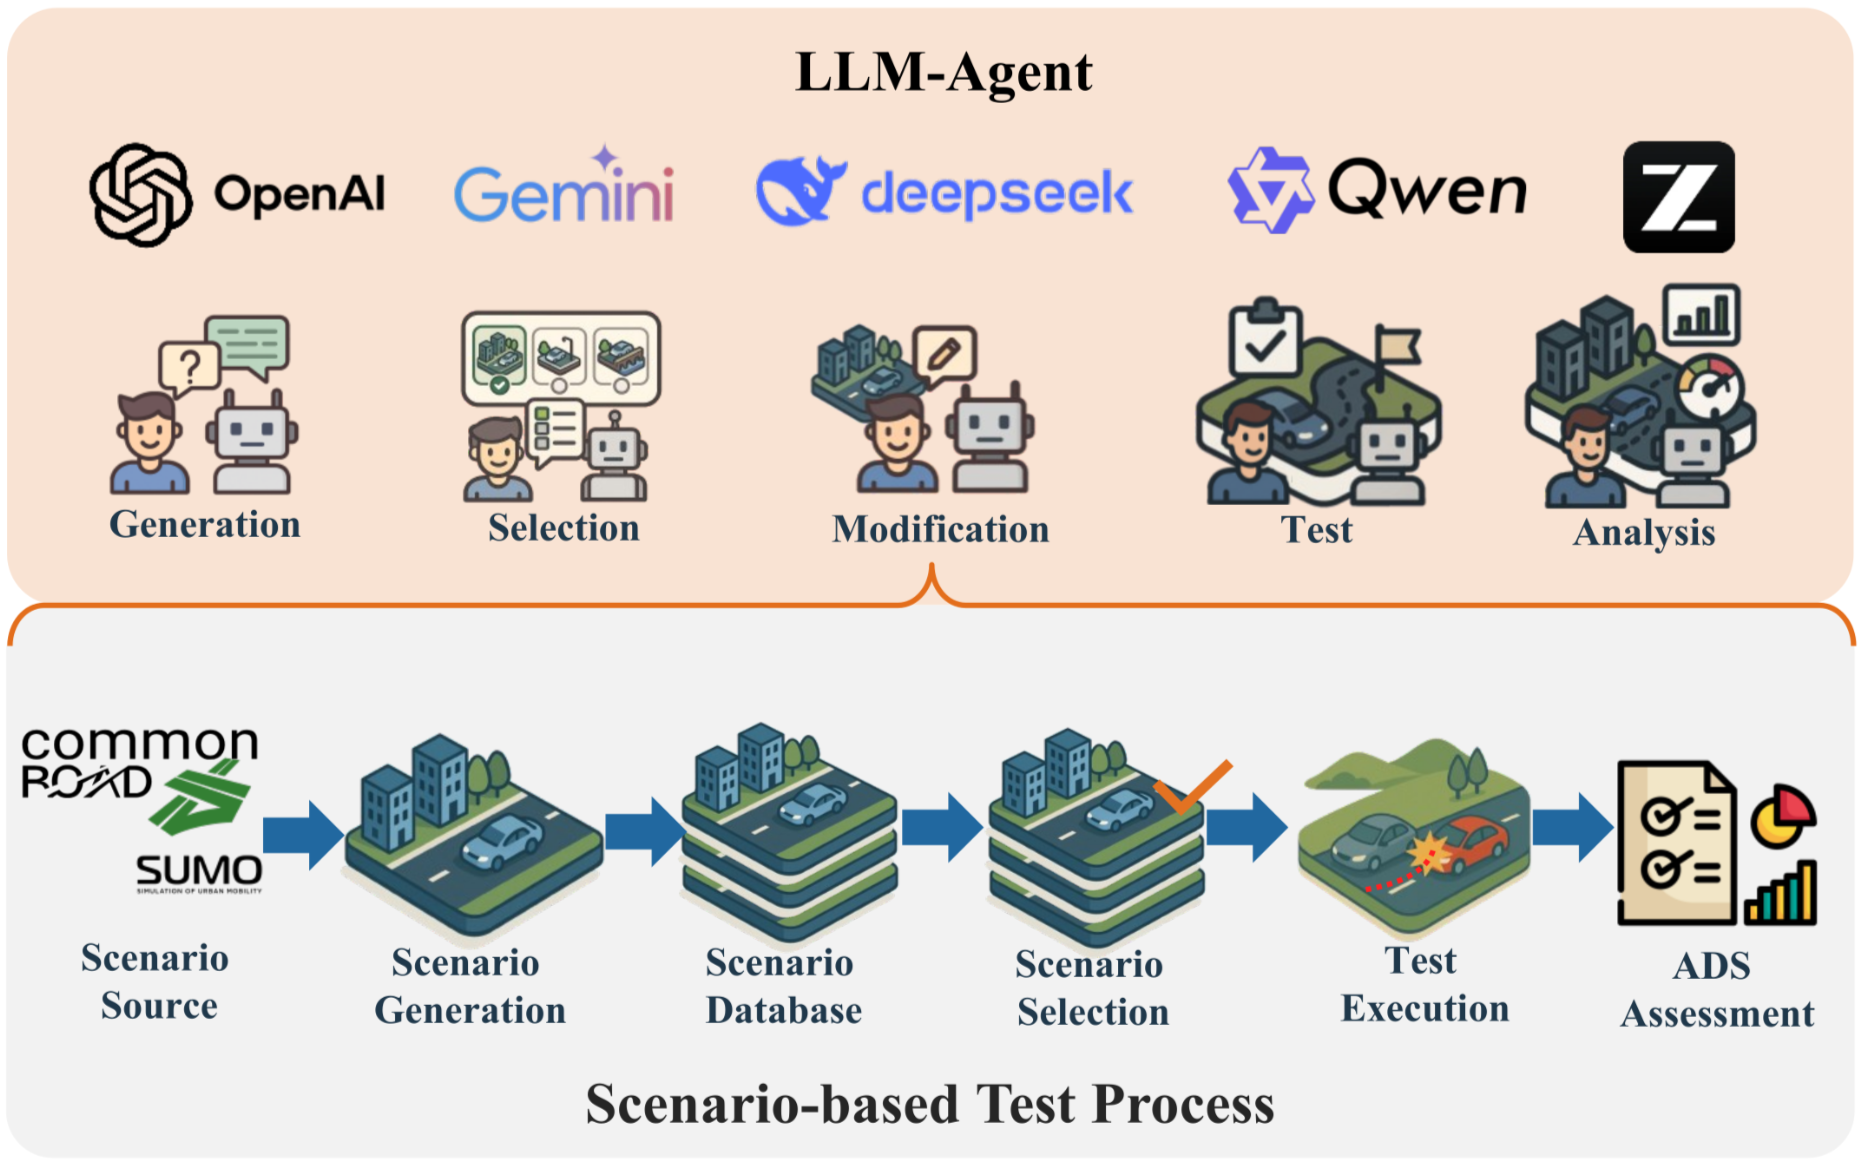 PlannerForge: LLM Agents for Scenario-Based Testing of Motion Planners in Autonomous DrivingIn 2026 Conference on Empirical Methods in Natural Language Processing (EMNLP), 2026Accepted
-
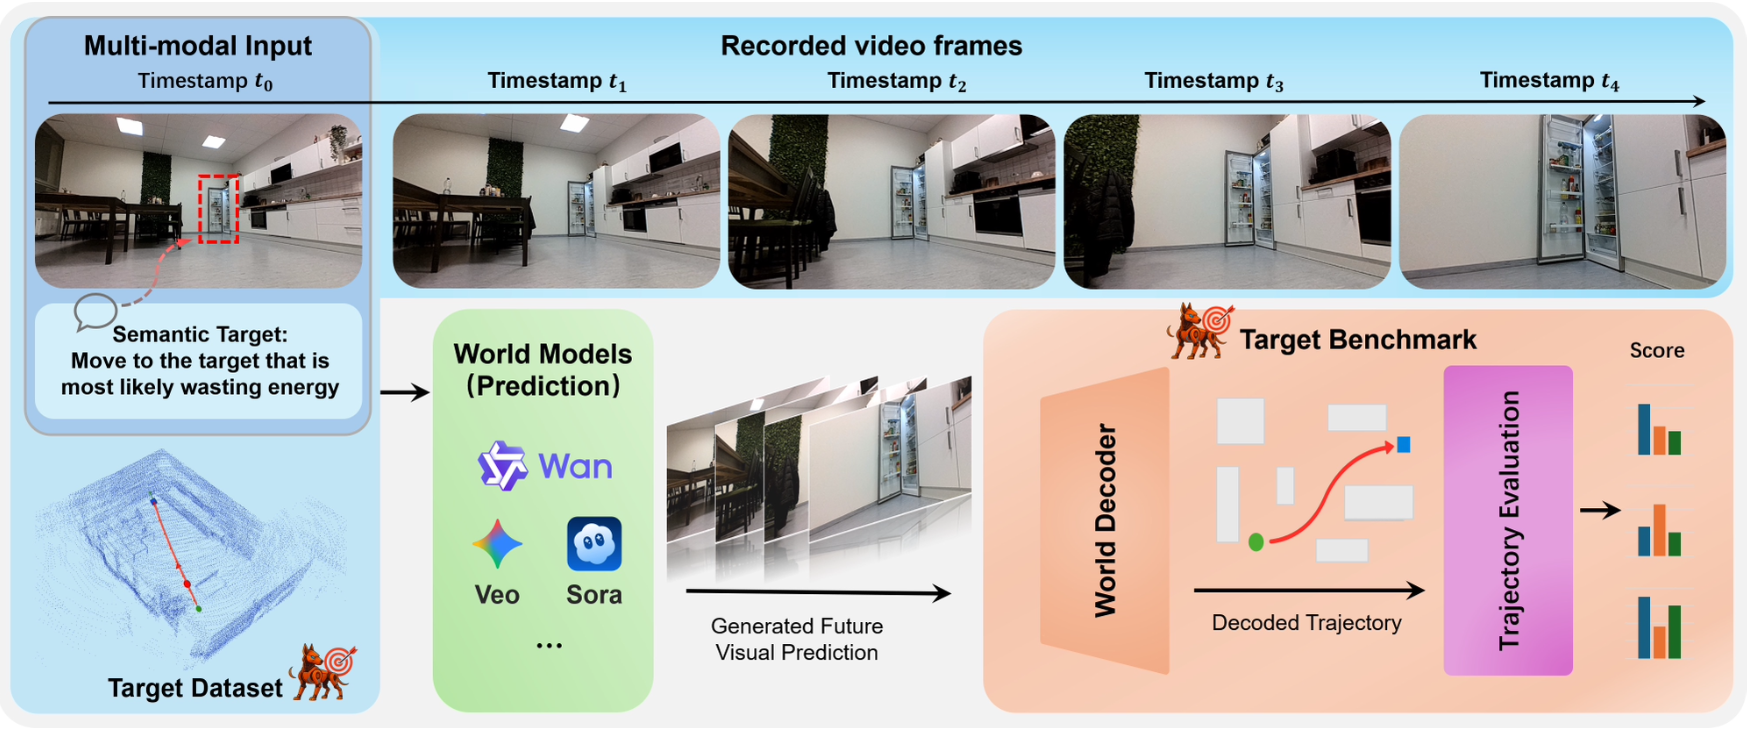 Target-Bench: Can Video World Models Achieve Mapless Path Planning with Semantic Targets?In Computer Vision – ECCV 2026, 2026
-
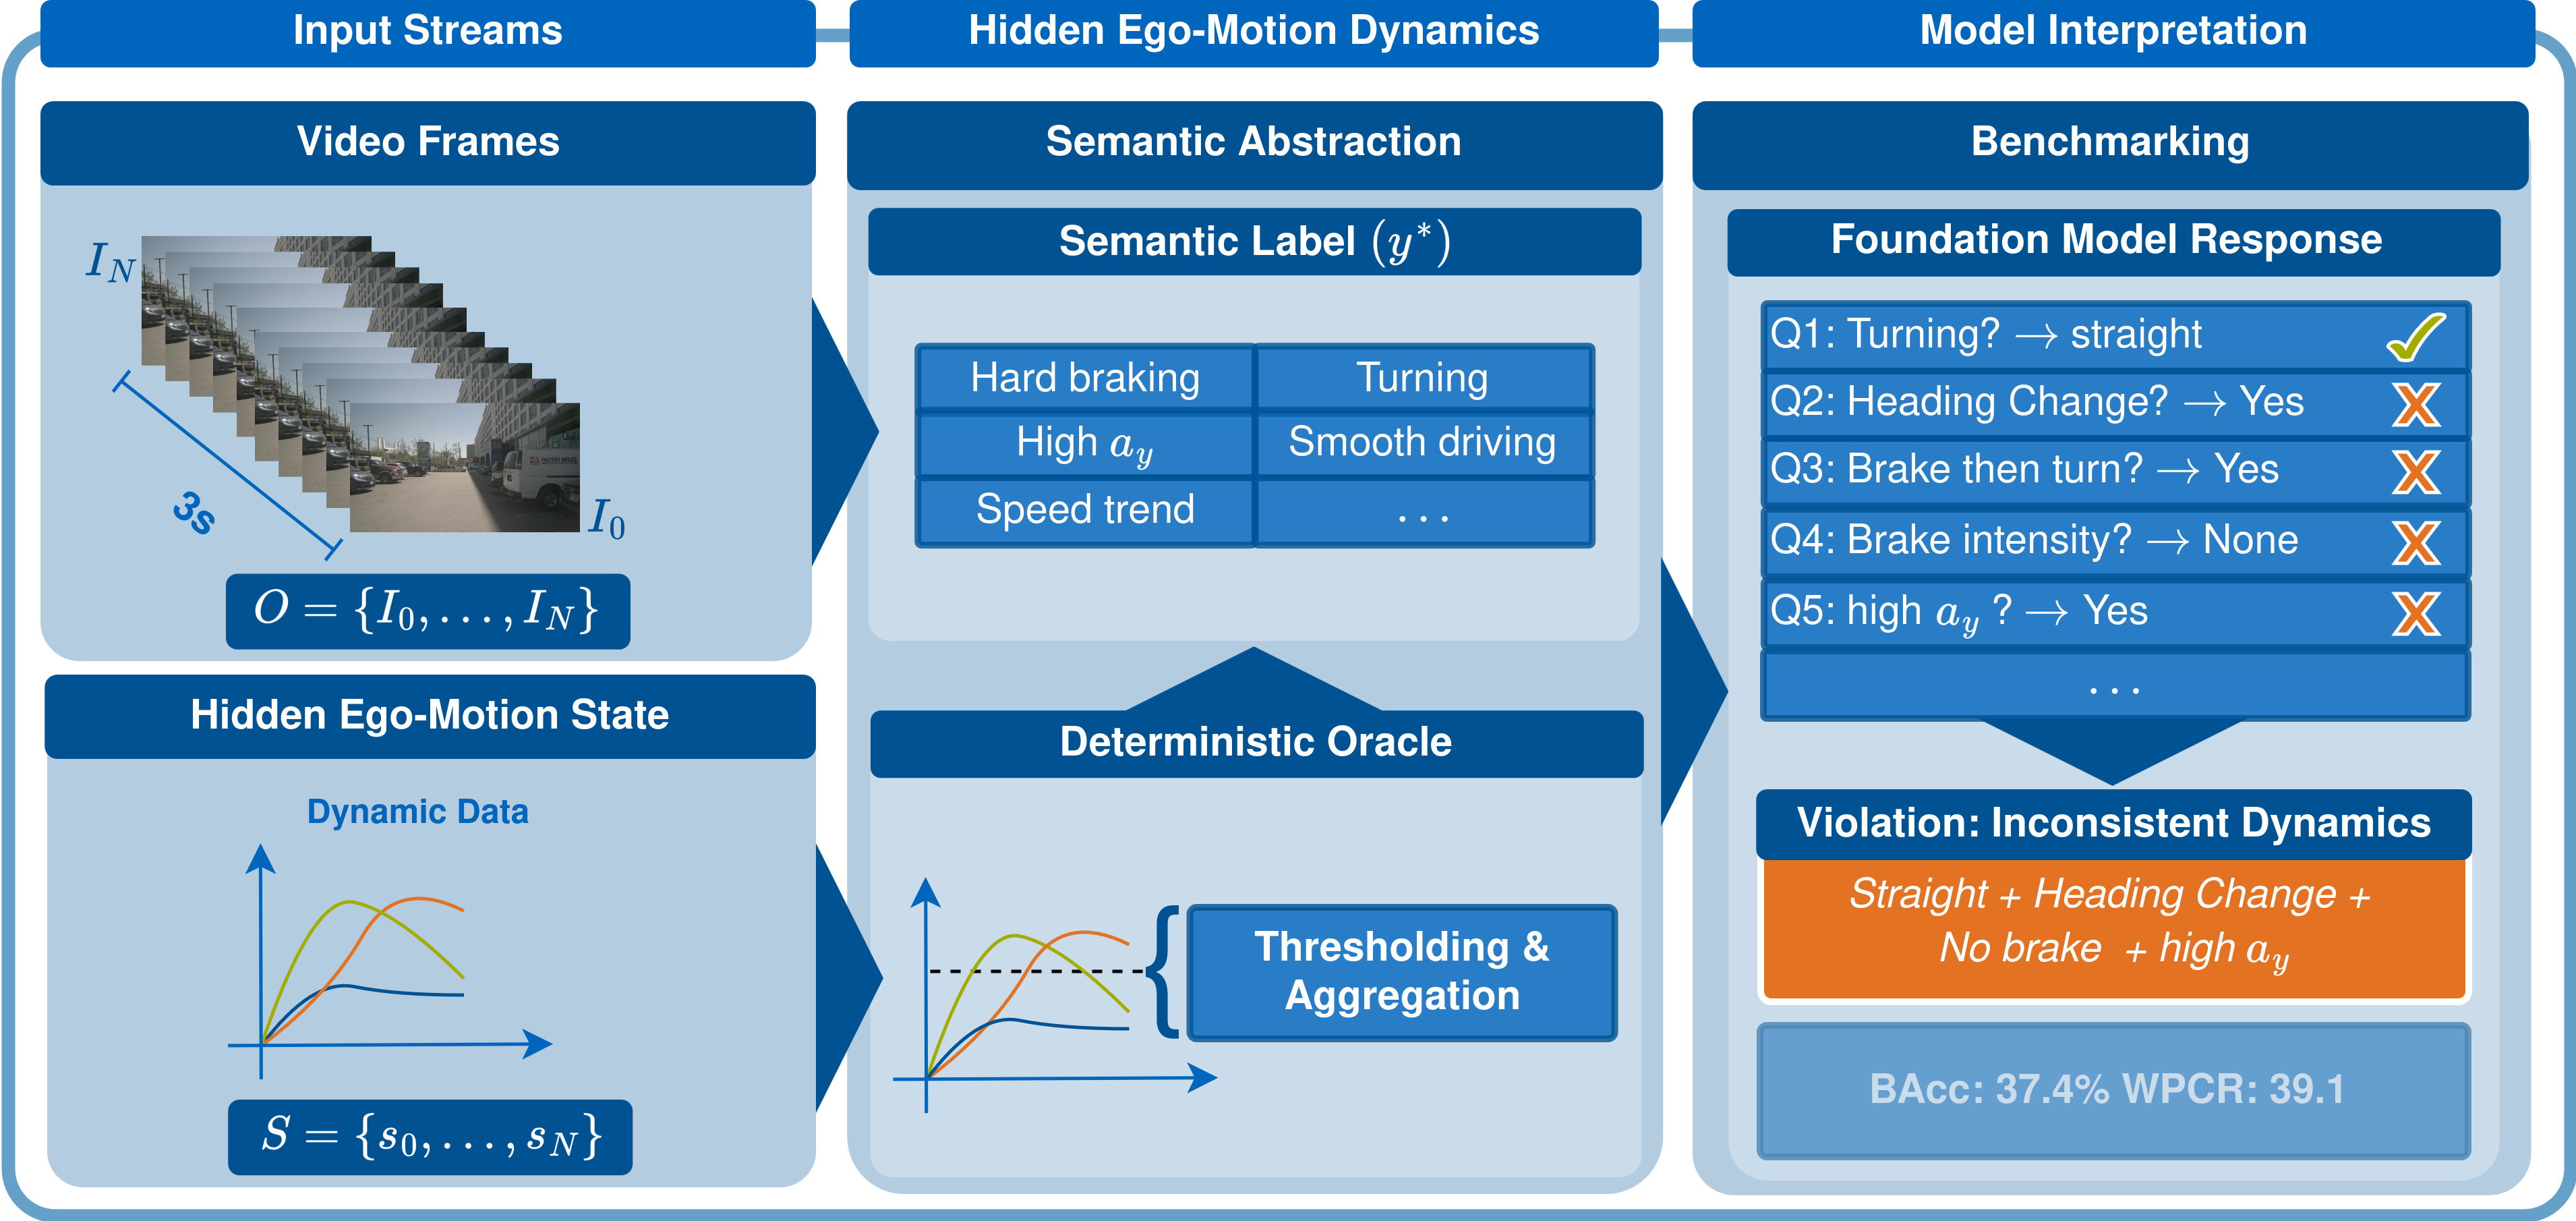 EgoDyn-Bench: Evaluating Ego-Motion Understanding in Vision-Centric Foundation Models for Autonomous DrivingIn Computer Vision – ECCV 2026, 2026
-
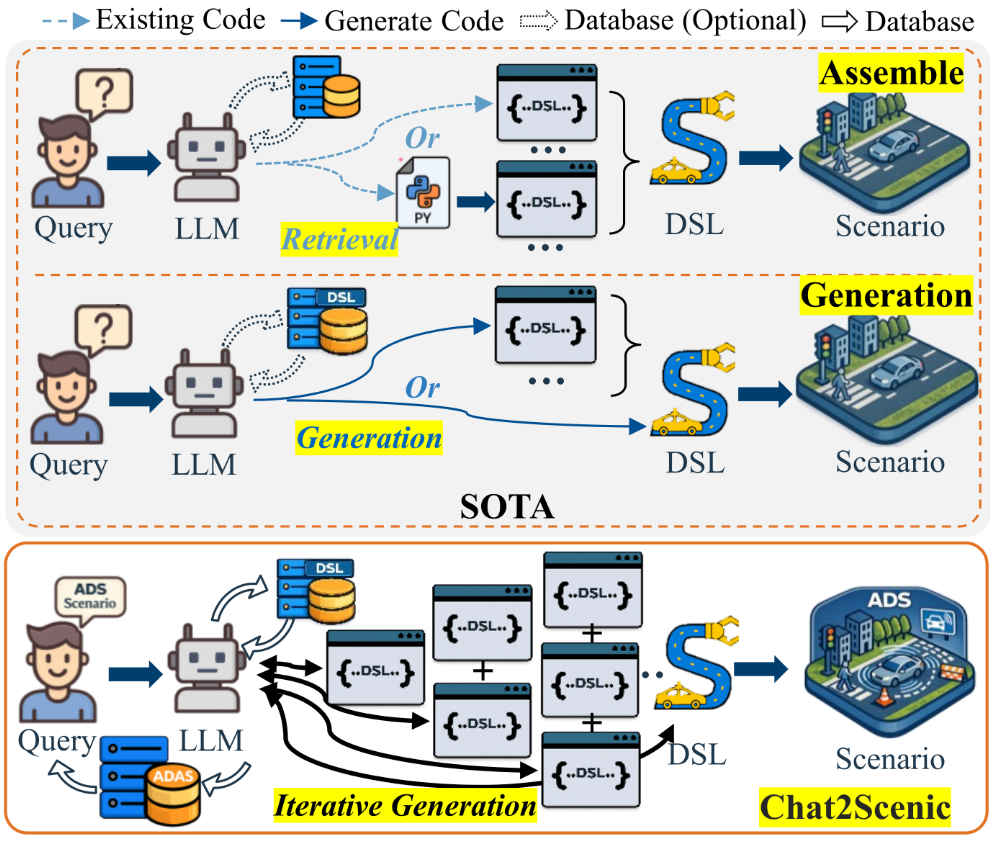 Chat2Scenic: An Iterative RAG-Based Framework for Scenario Generation in Autonomous DrivingIn 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026Accepted
-
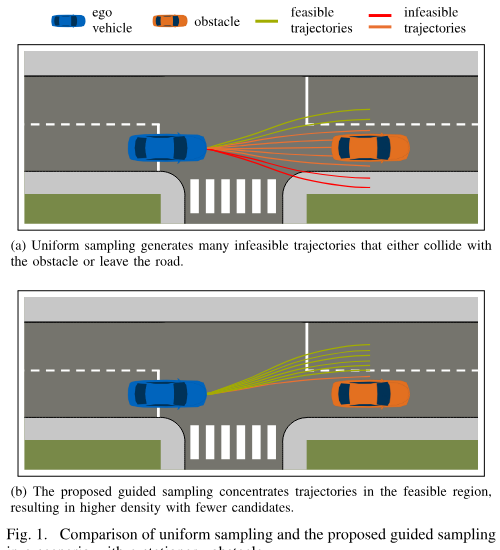 Learning to Sample: Reinforcement Learning-Guided Sampling for Autonomous Vehicle Motion PlanningIn 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026Accepted
-
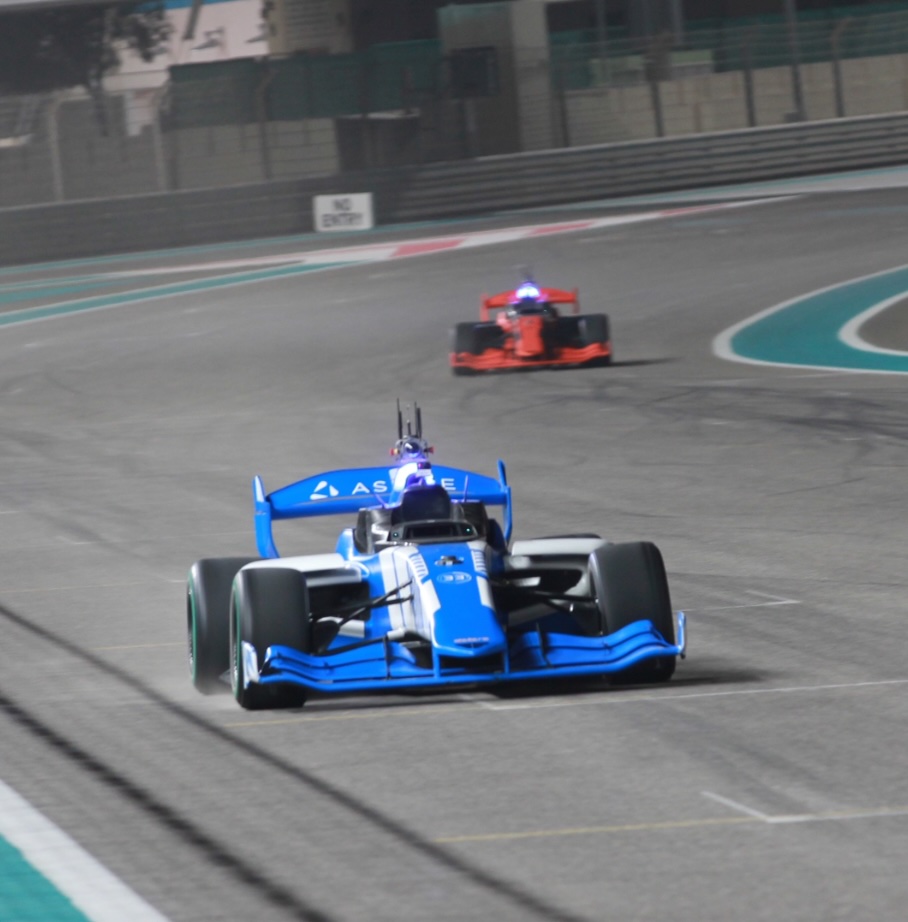
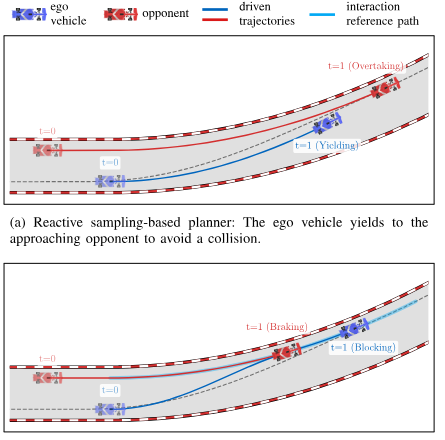 A Hybrid Sampling-Based Trajectory Planner with Game-Theoretic Guidance for Autonomous RacingIn 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026Accepted
-
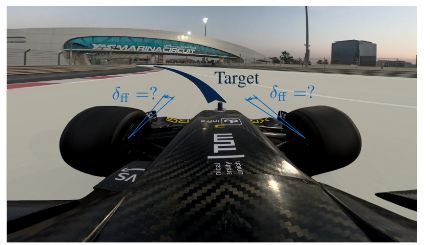 Benchmarking Empirical and Learning-Based Approaches for Feedforward Steering Control in Autonomous RacingIn 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026Accepted
-
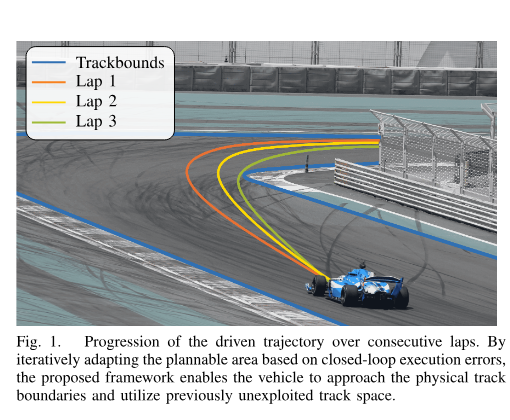 Control-Informed Constraint Adaptation in Minimum-Time Trajectory Planning for Autonomous RacingIn 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026Accepted
-
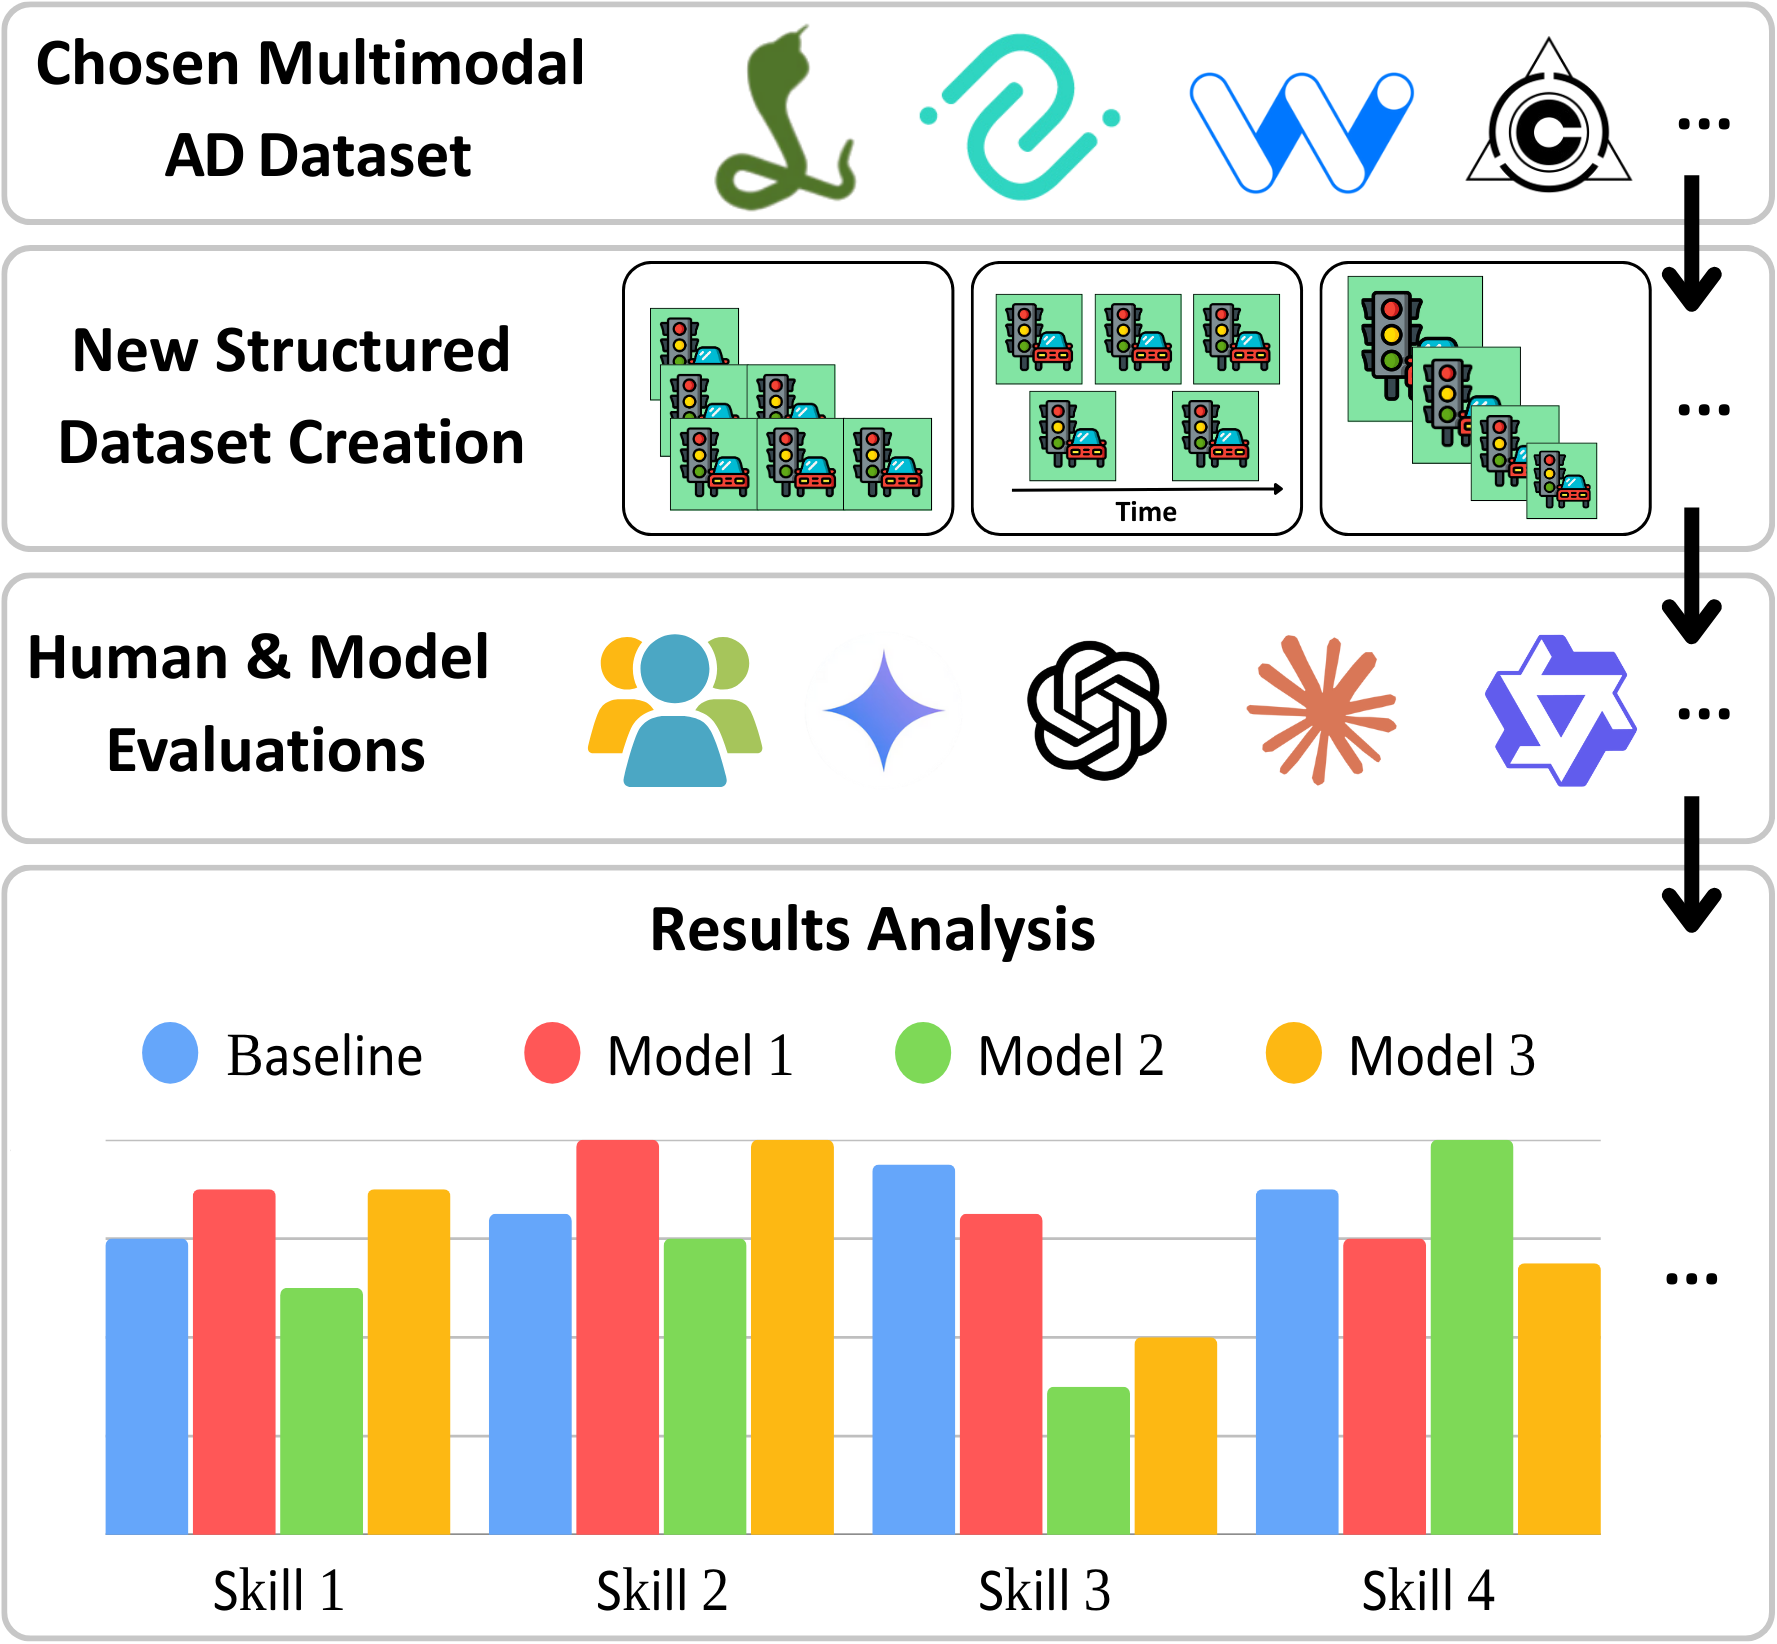 How Well Do Vision-Language Models Understand Sequential Driving Scenes? A Sensitivity StudyIn 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026Accepted
-
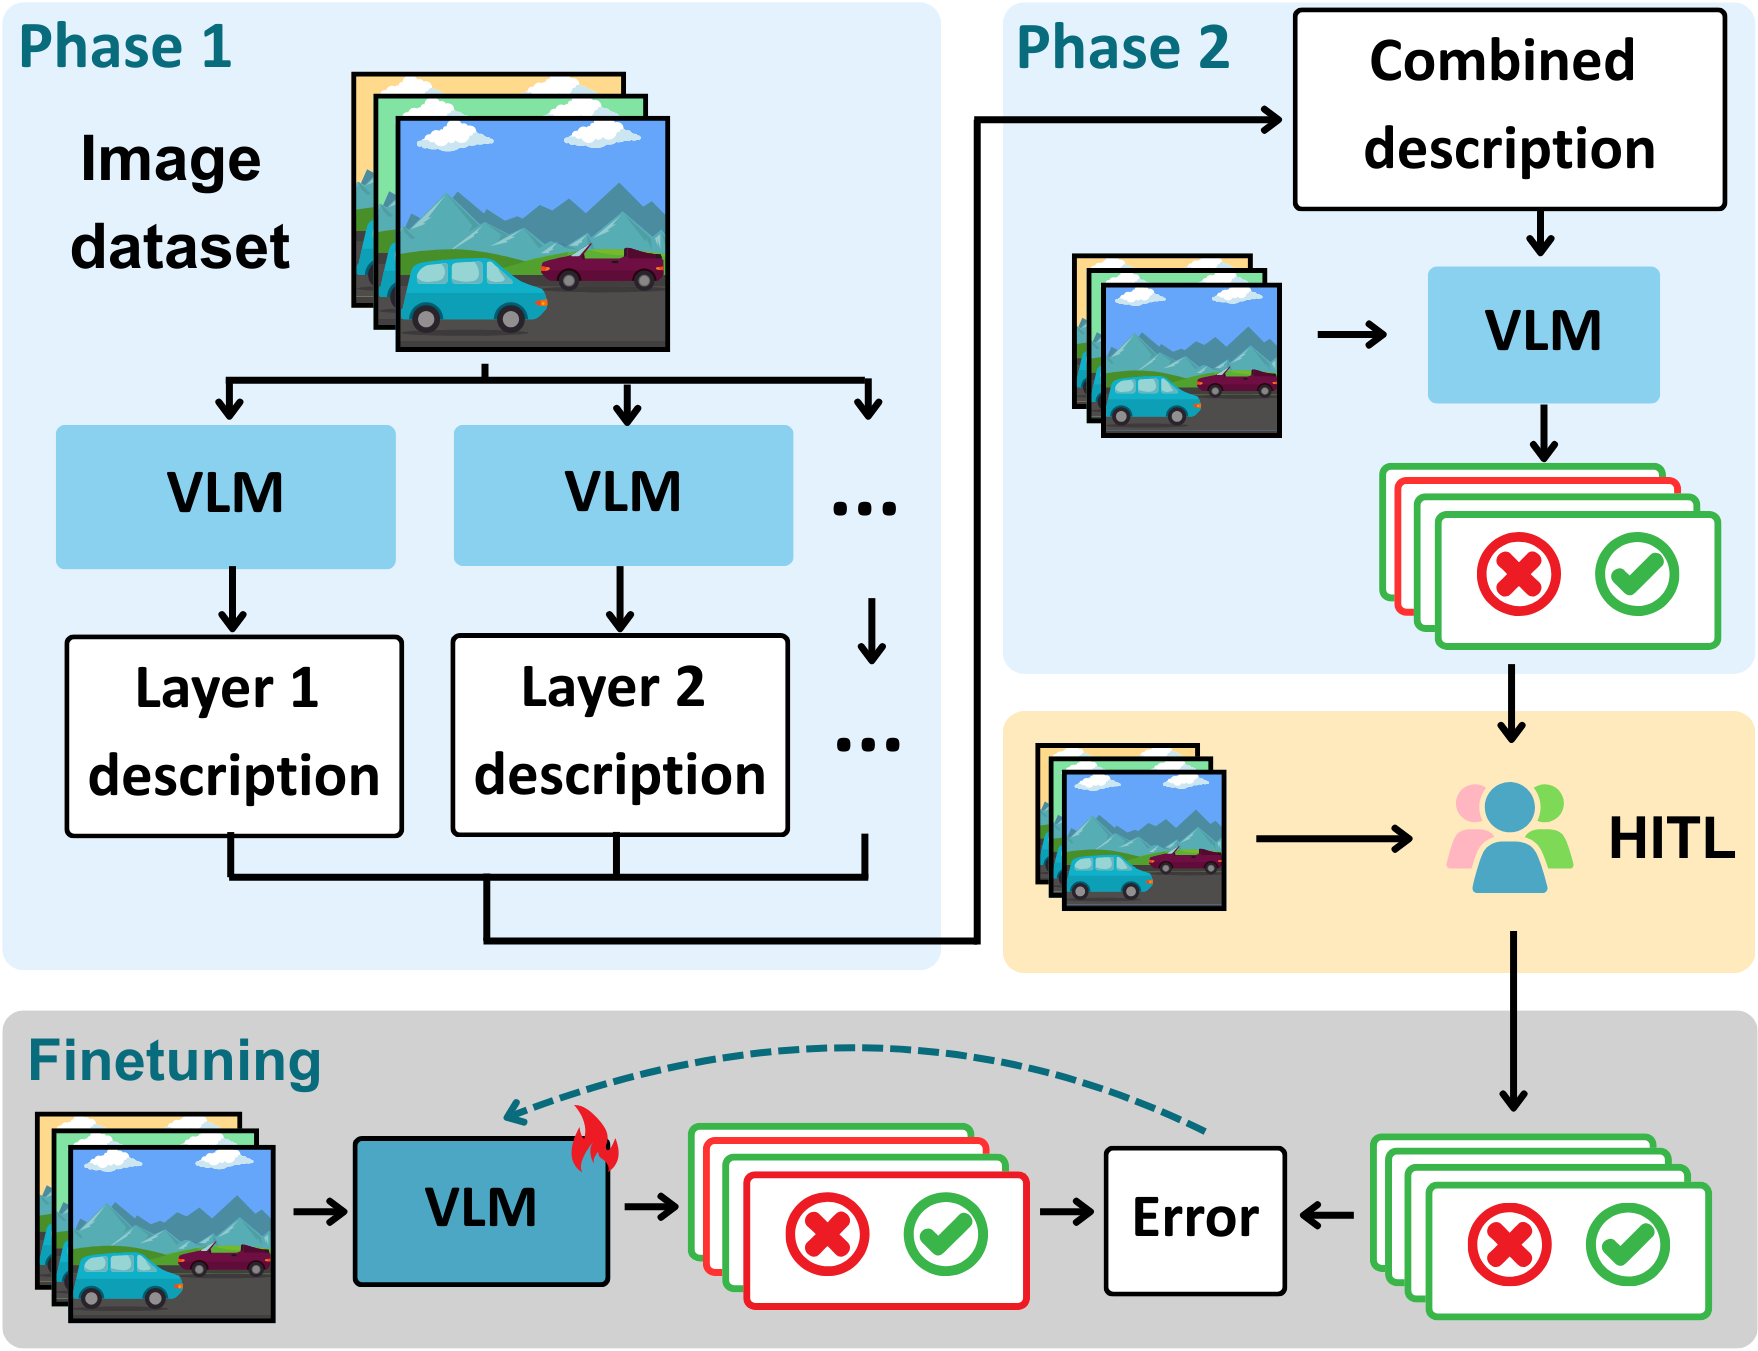 Can VLMs Unlock Semantic Anomaly Detection? A Framework for Structured ReasoningIn 2026 IEEE 29th International Conference on Intelligent Transportation Systems (ITSC), 2026Accepted
-
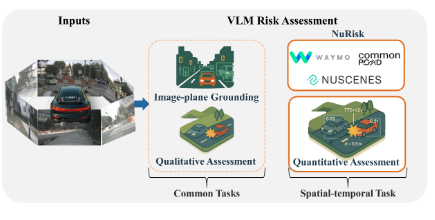 NuRisk: A Visual Question Answering Dataset for Agent-Level Risk Assessment in Autonomous DrivingIn 2026 IEEE International Conference on Robotics and Automation (ICRA), 2026Accepted
-
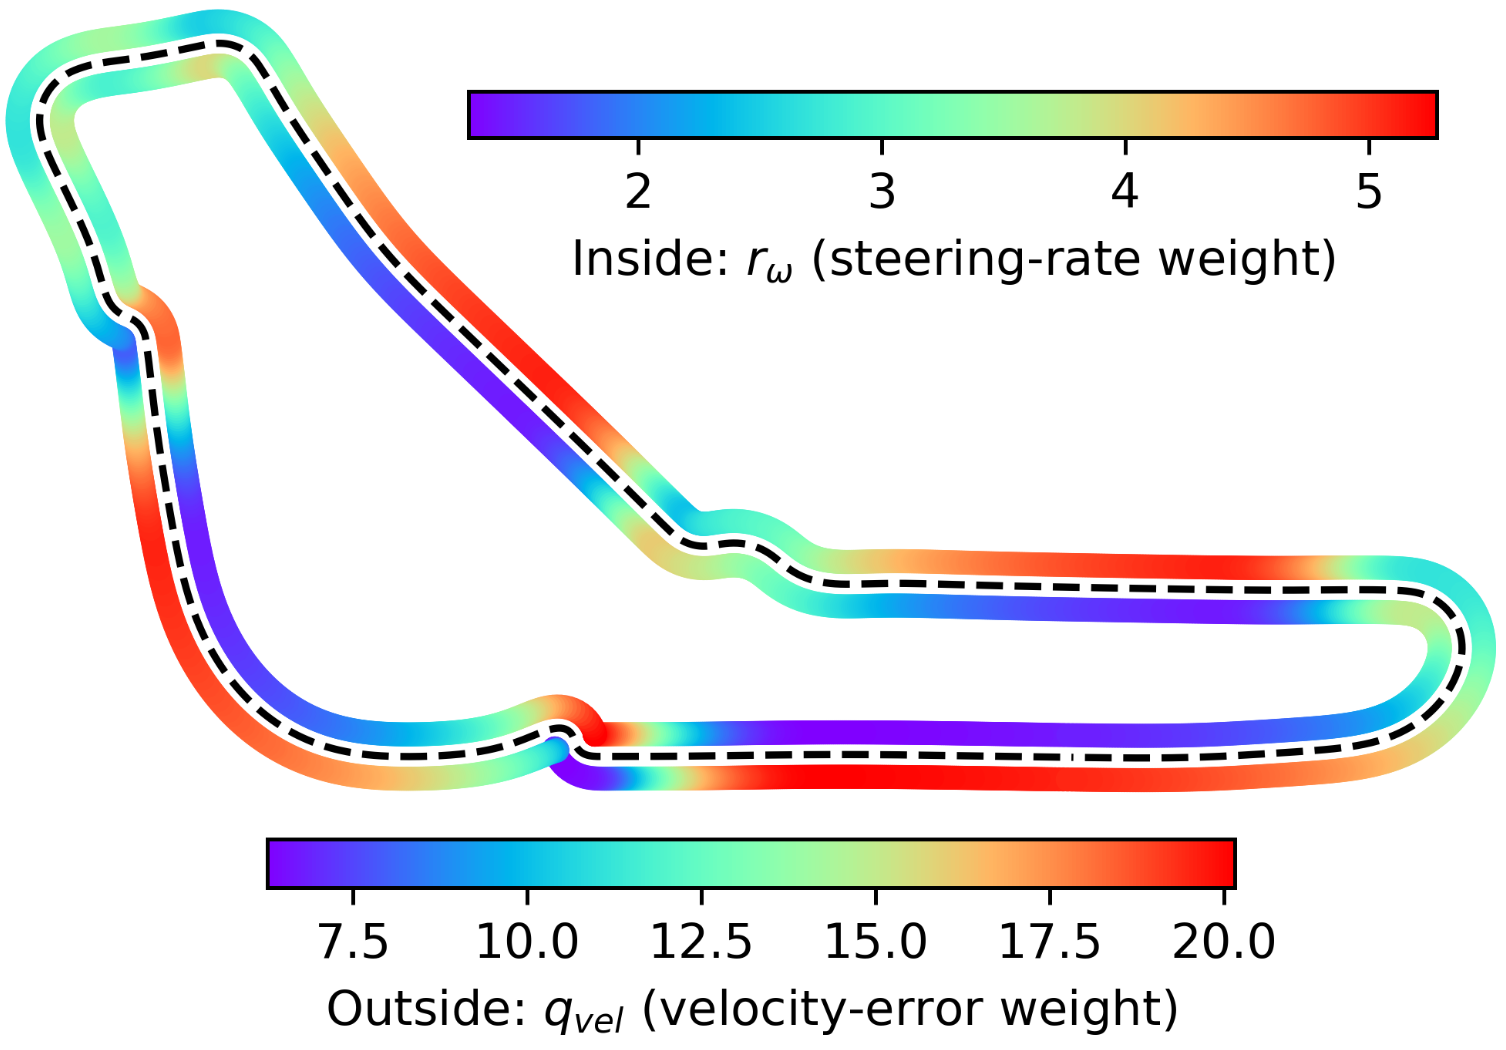 Gradient-Based Policy Learning for Context-Aware Differentiable Weights-Varying Nonlinear MPCIn AUTOMATICA.IT 2026, 2026
-
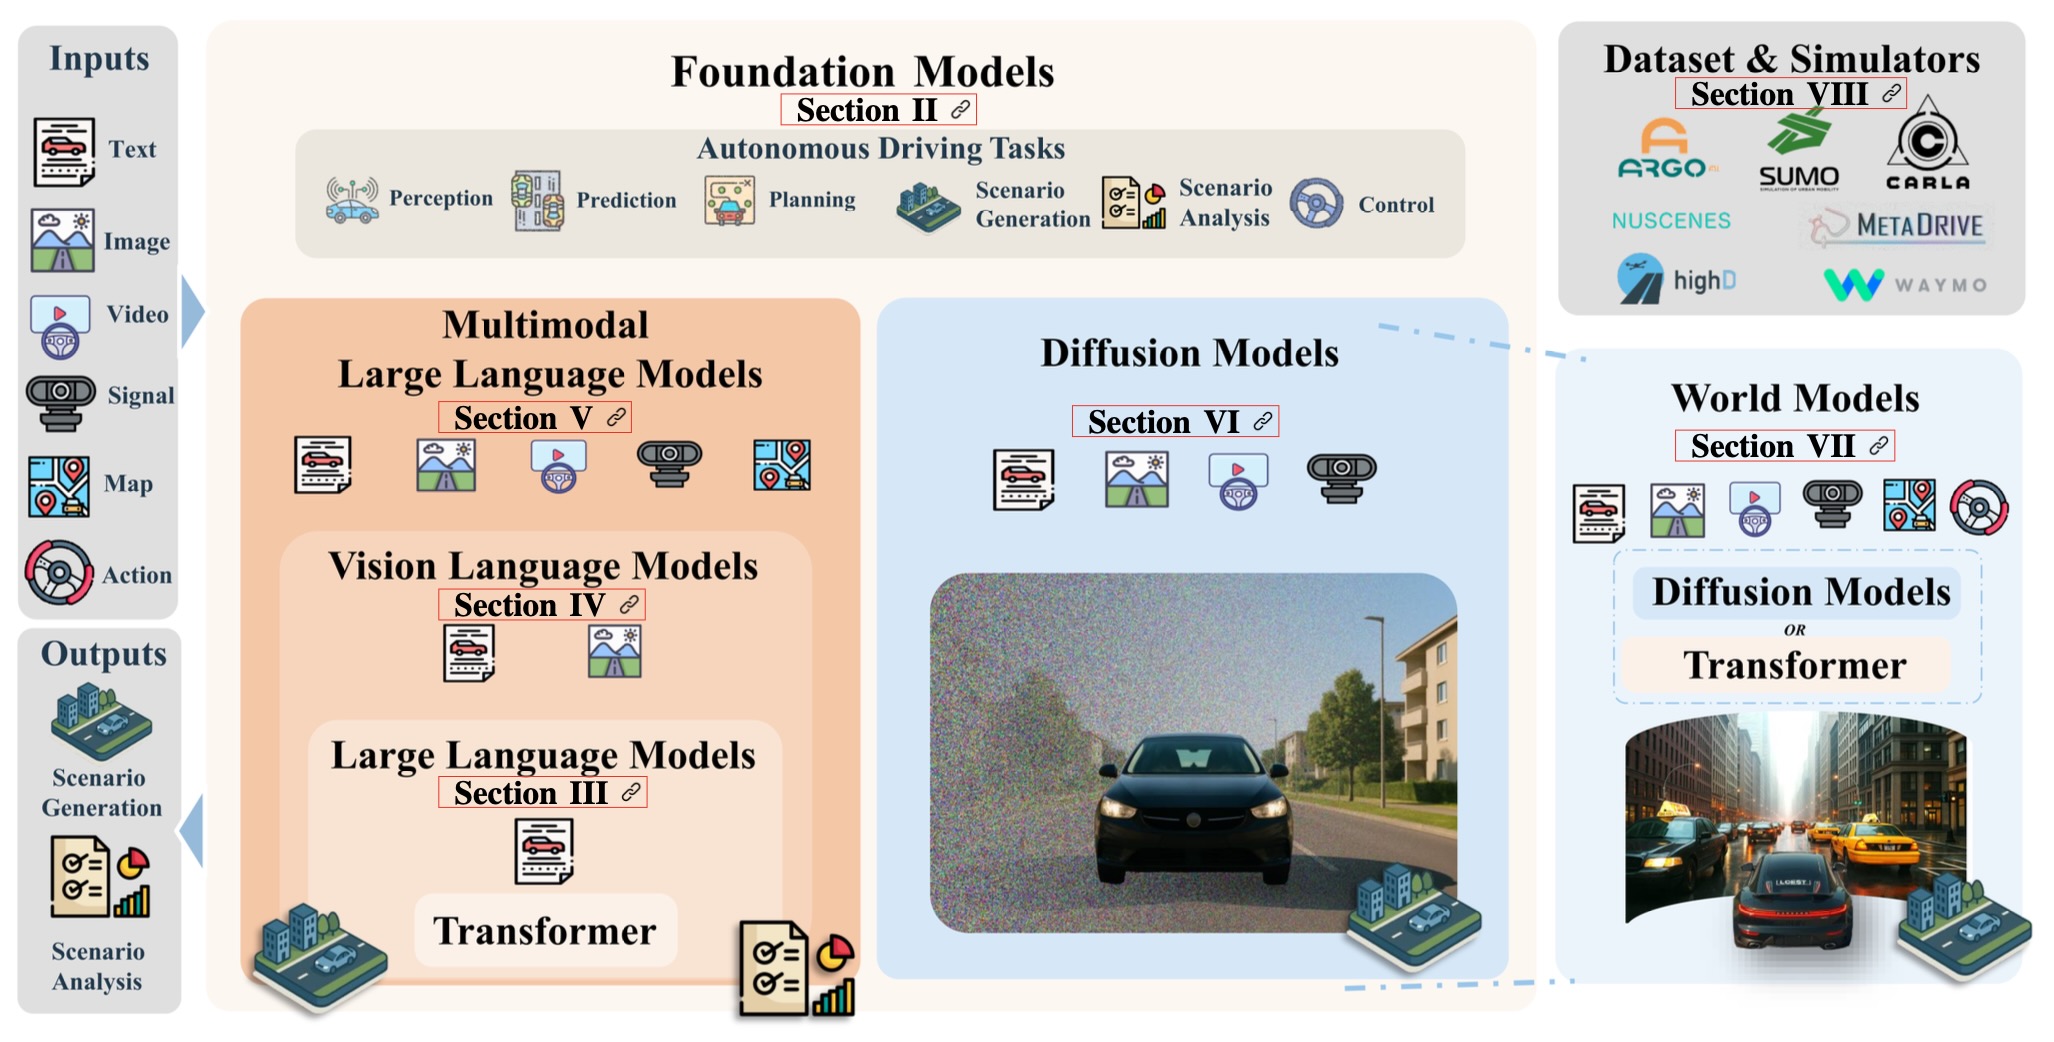
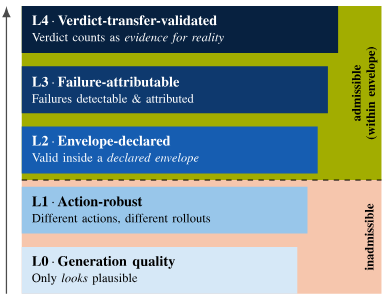 Validate the Dream Before You Trust Its Verdict: Admissibility for World-Model SimulatorsIn Workshop on Robot World Models, Robotics: Science and Systems (RSS) 2026, 2026
- Chat2Scenic: An Iterative RAG-Based Framework for Scenario Generation in Autonomous DrivingIn DriveX Workshop, European Conference on Computer Vision (ECCV) 2026, 2026
-
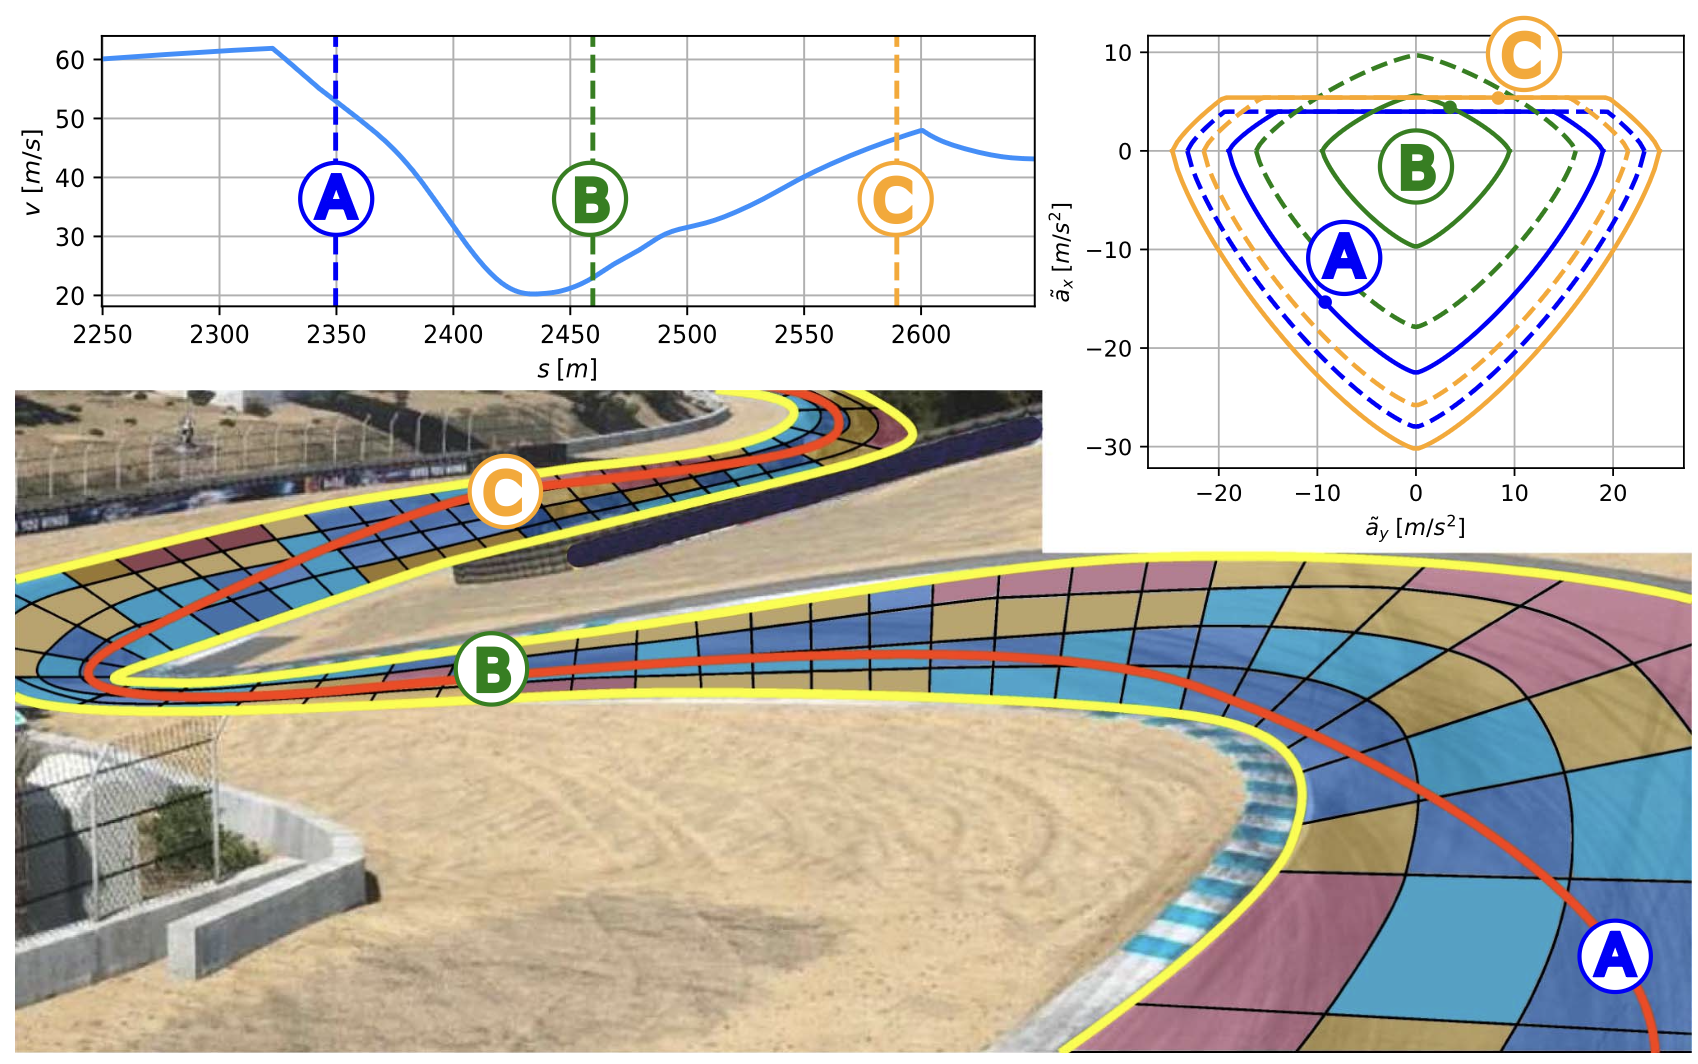
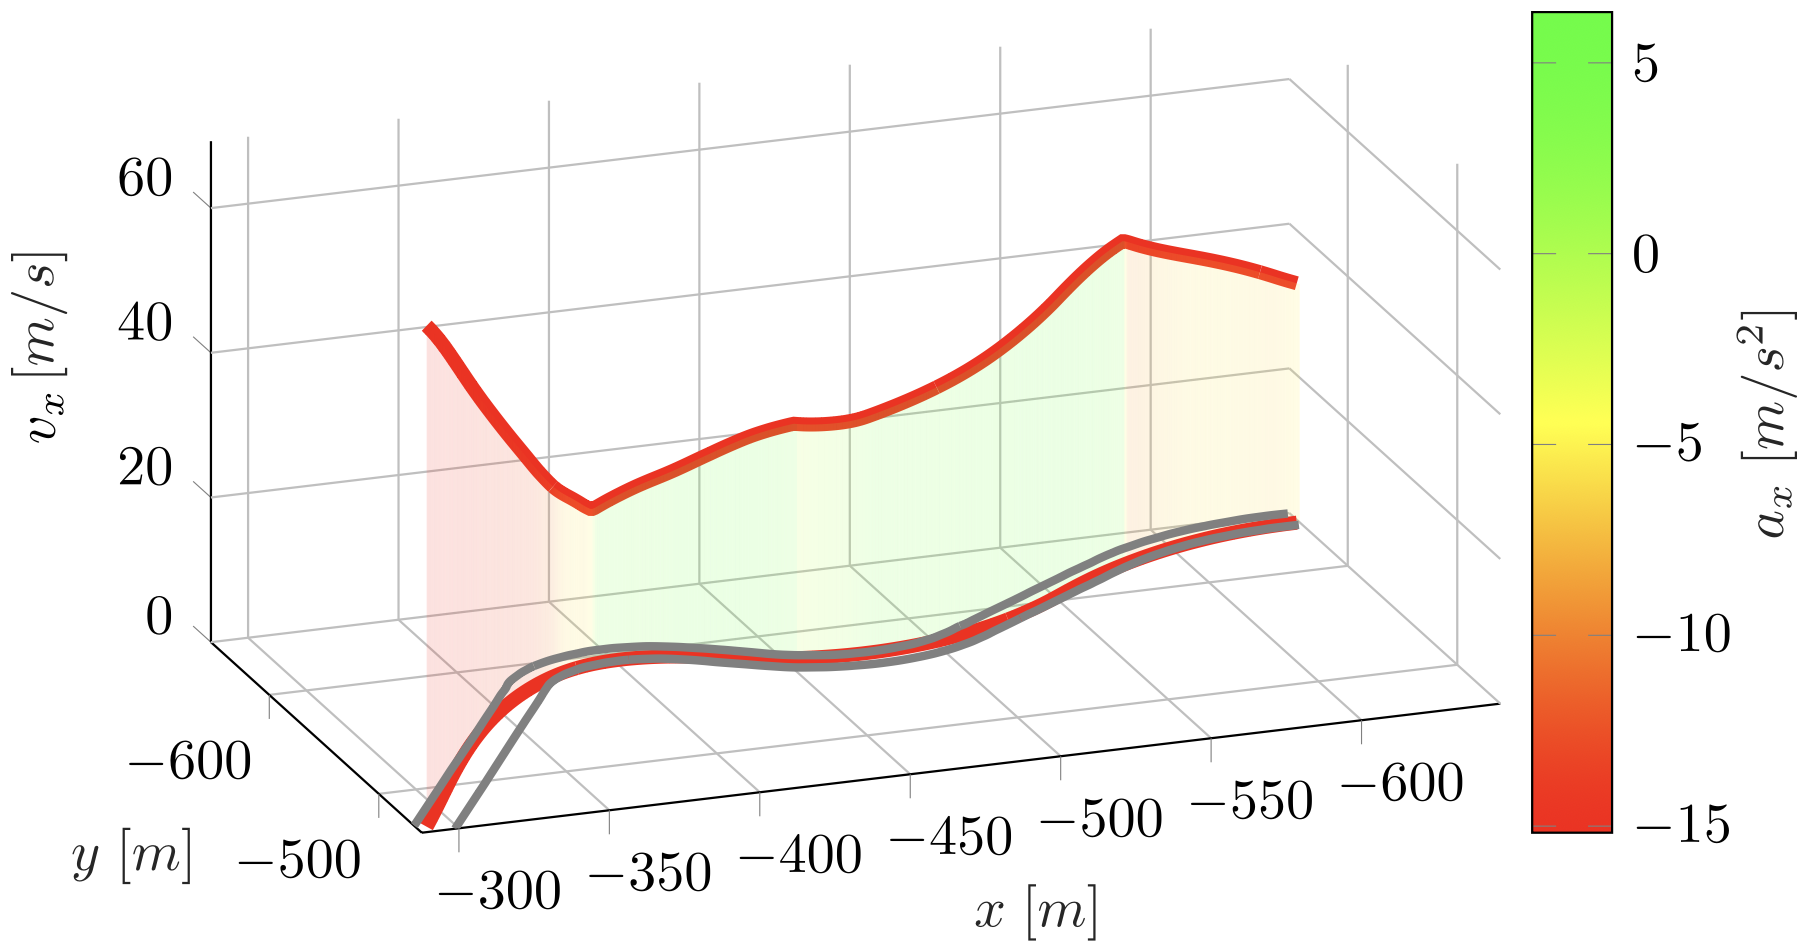 Fast and Flexible Velocity Planning for Time-Optimal ManeuversIn Frontiers of Optimization for Robotics Workshop, IEEE International Conference on Robotics and Automation (ICRA) 2026, 2026
- FBGA: A Forward-Backward Method for Online Time-Optimal Velocity Planning with Generic Acceleration ConstraintsIn 2nd German Robotics Conference 2026, 2026
-
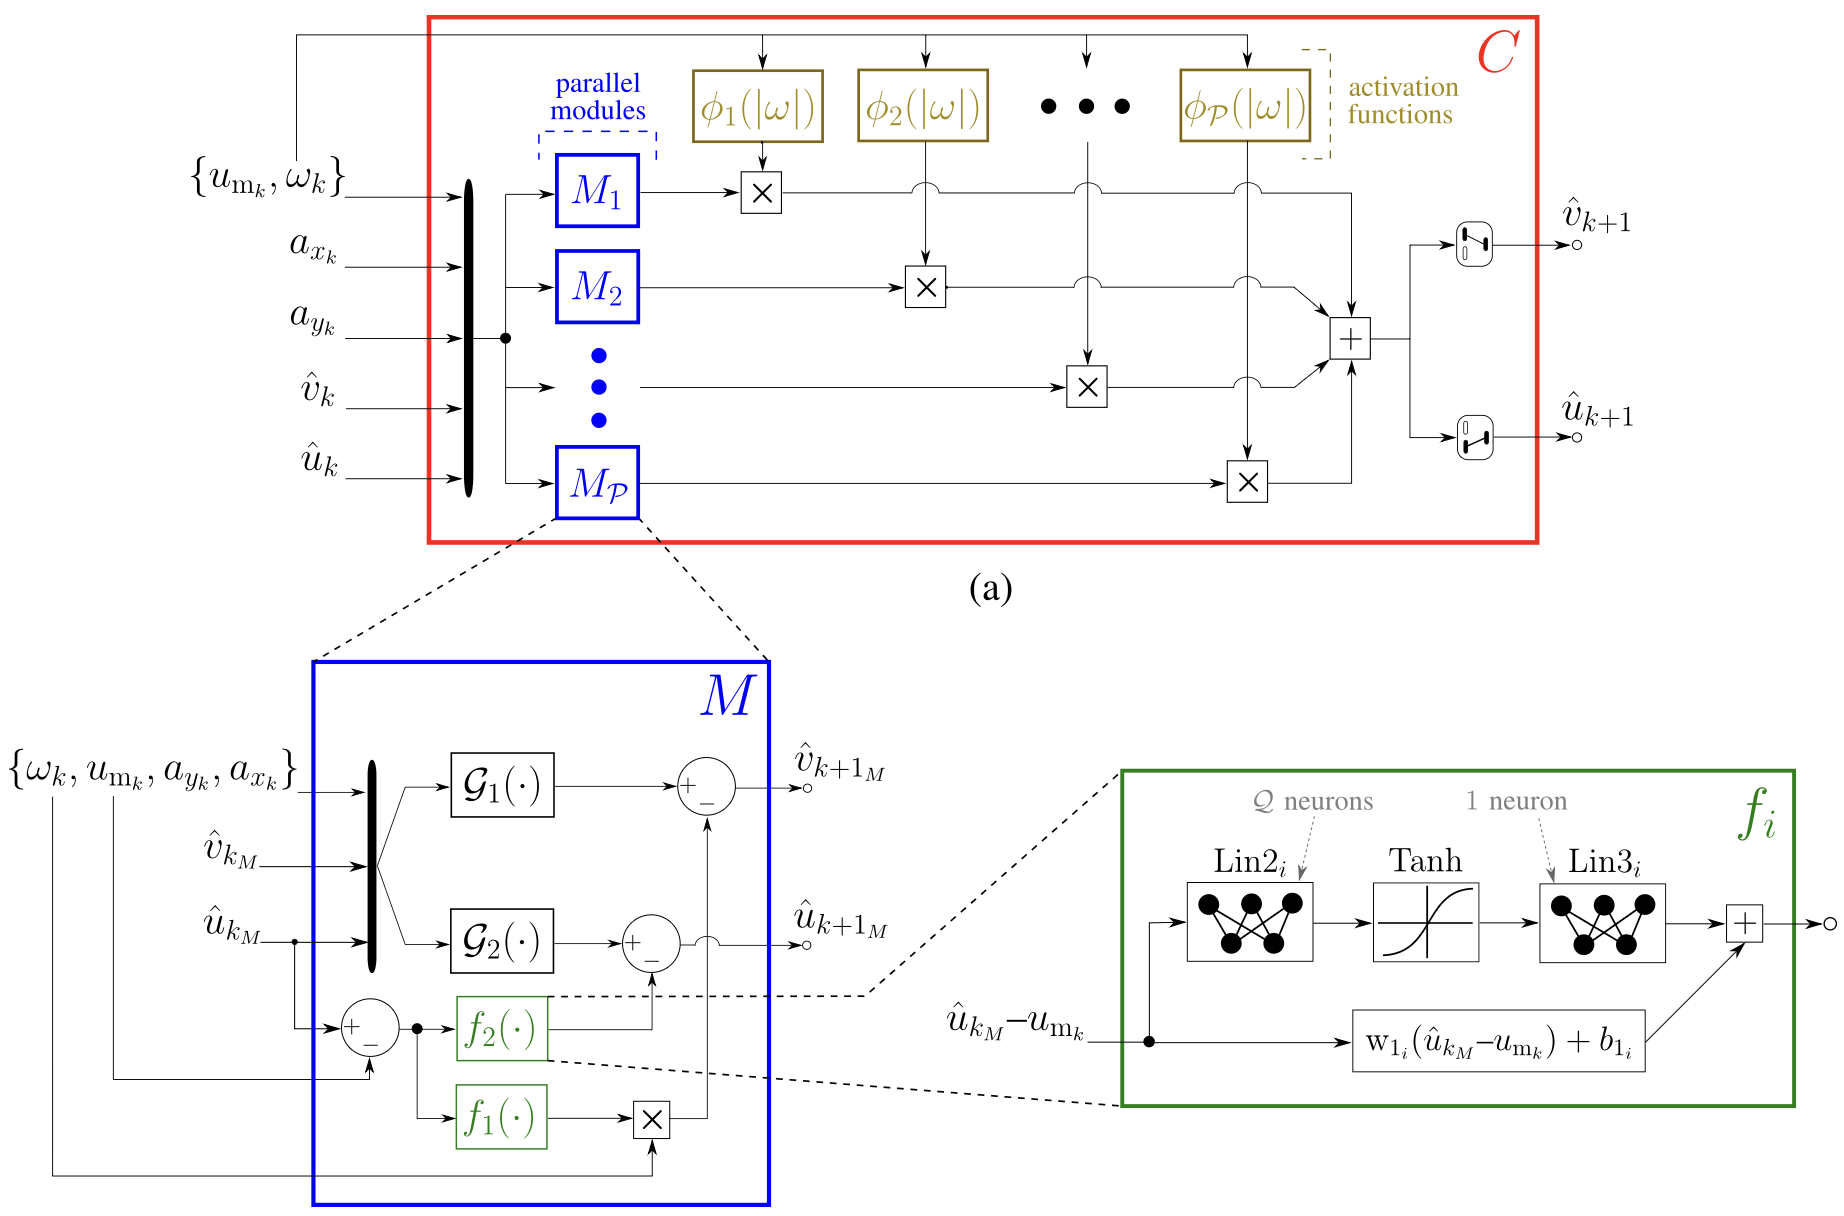
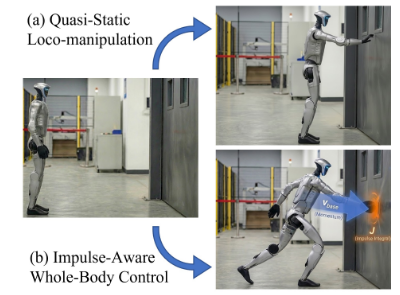 Bridging the Loco-Manipulation Disconnect: Dynamic Whole-Body Impulse Control on Floating-Base RobotsIn 2nd German Robotics Conference 2026, 2026
-
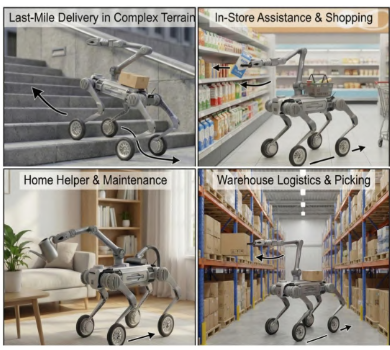 Towards Whole-Body VLA: A Scalable Data Collection Framework for Quadrupedal Mobile ManipulatorsIn 2nd German Robotics Conference 2026, 2026
2025
-
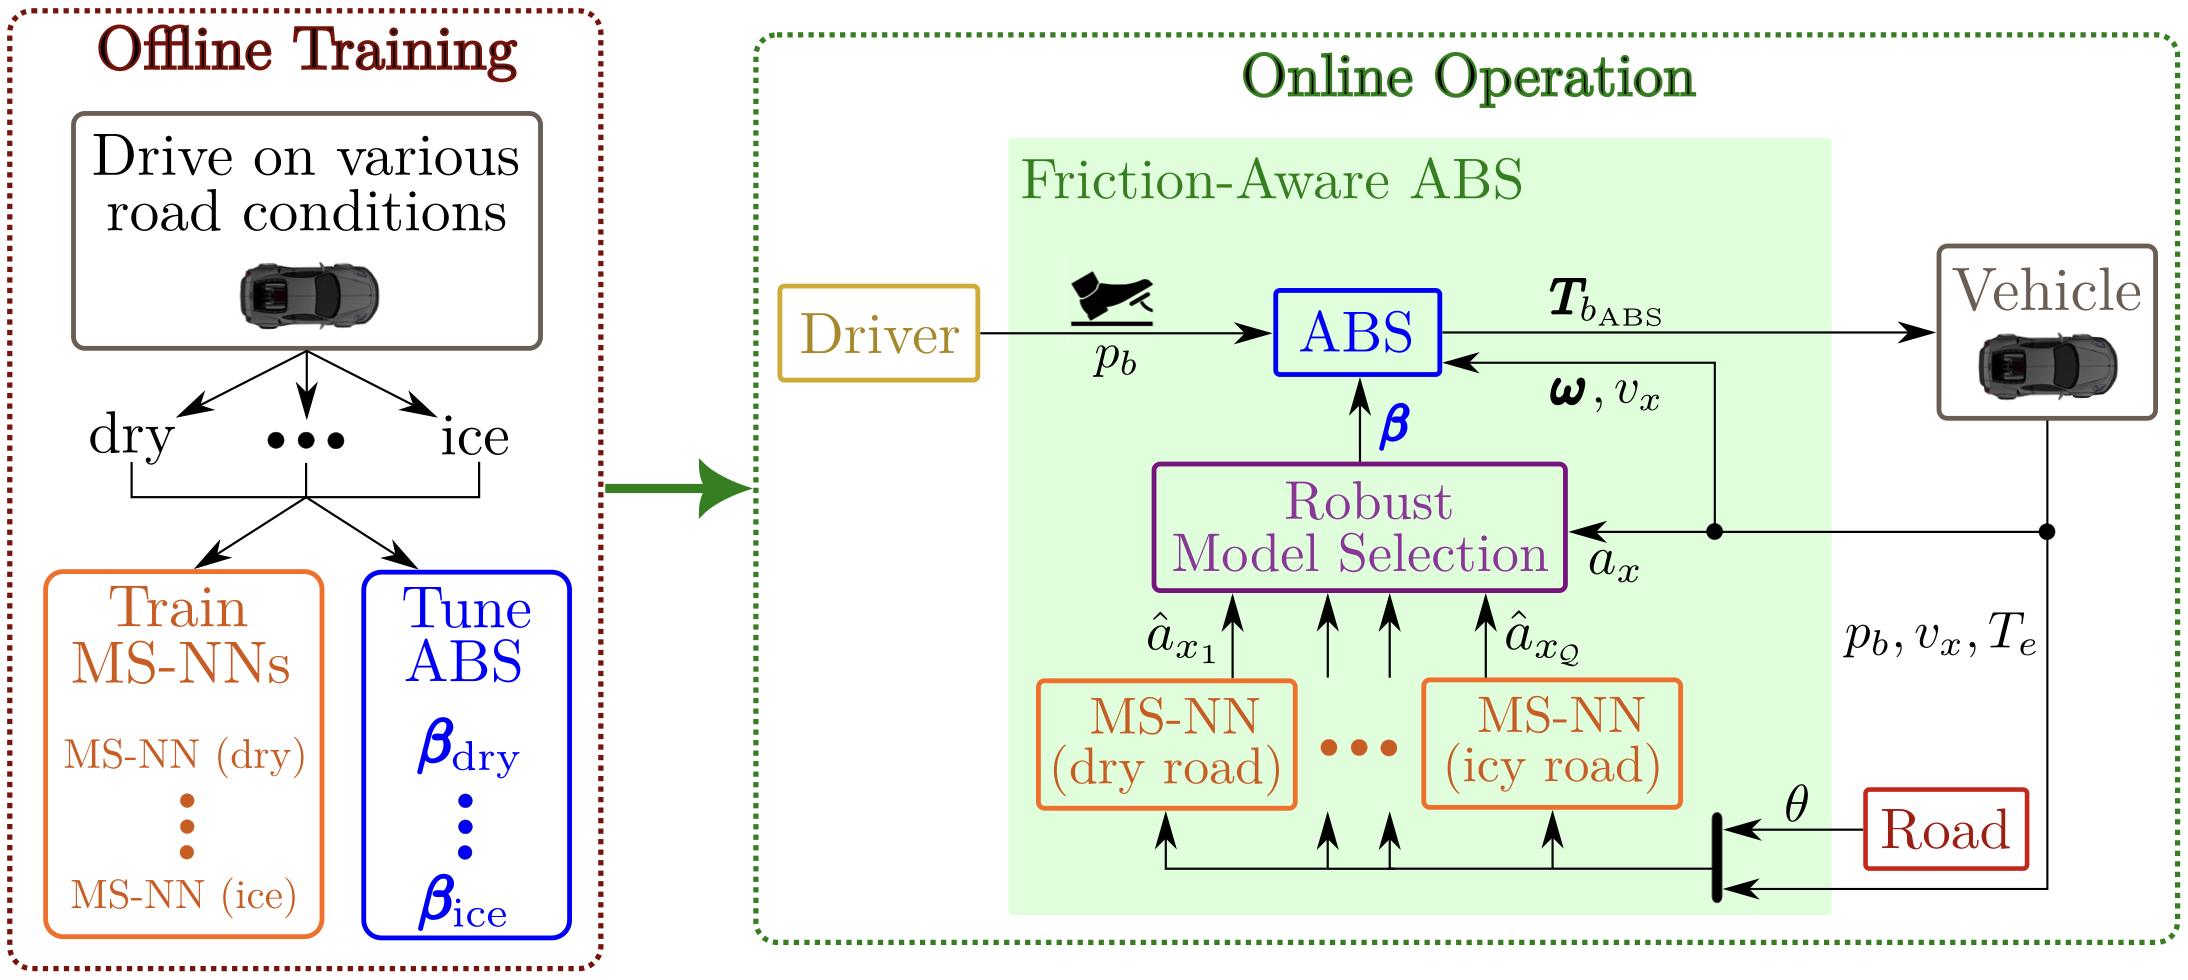 Model-Structured Neural Networks for Road Friction-Aware Anti-Lock Braking SystemsIn AUTOMATICA.IT 2025, 2025
-
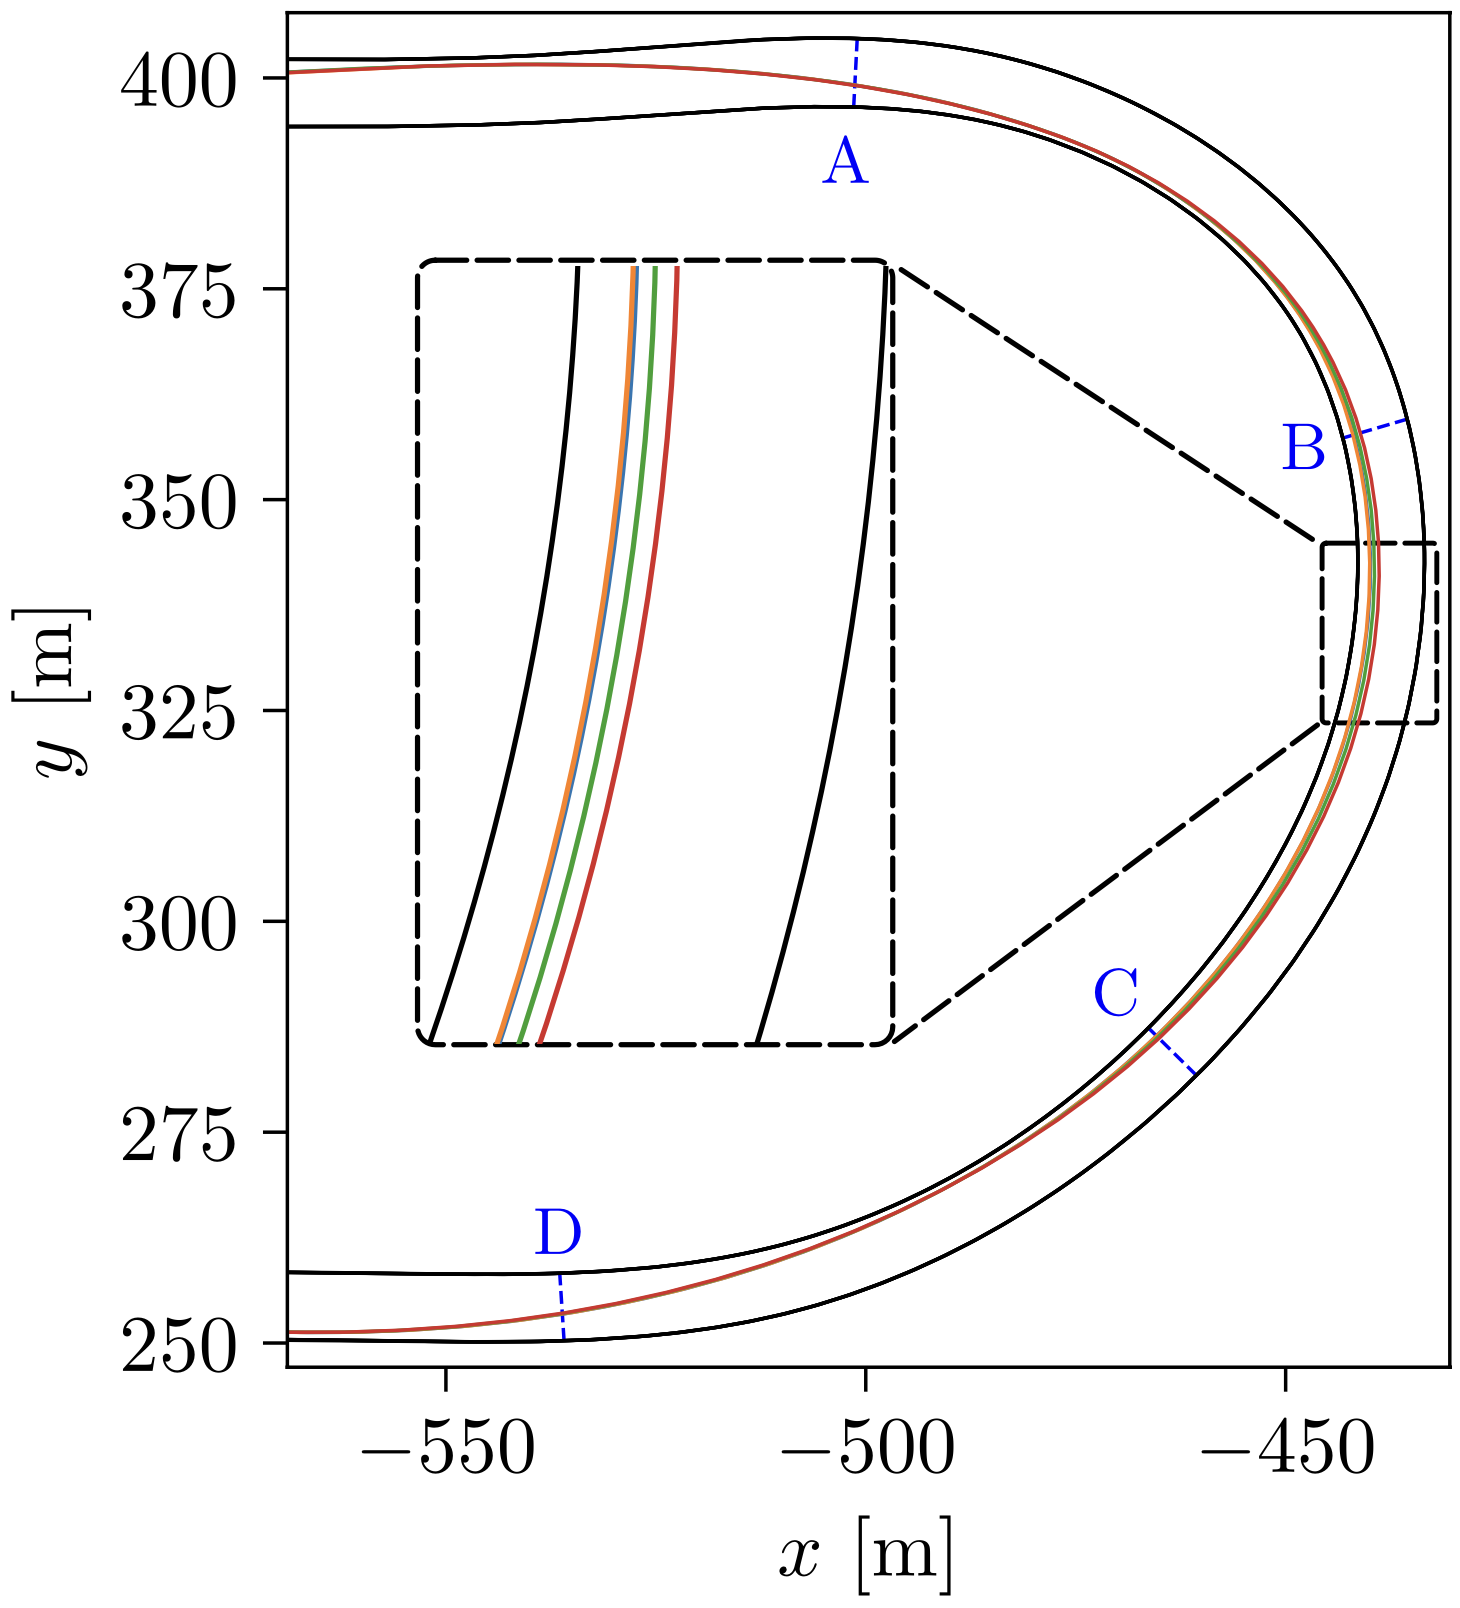 From Early to Late Apexes: Biasing the Driving Style of Online Time-Optimal Maneuver PlanningIn AUTOMATICA.IT 2025, 2025
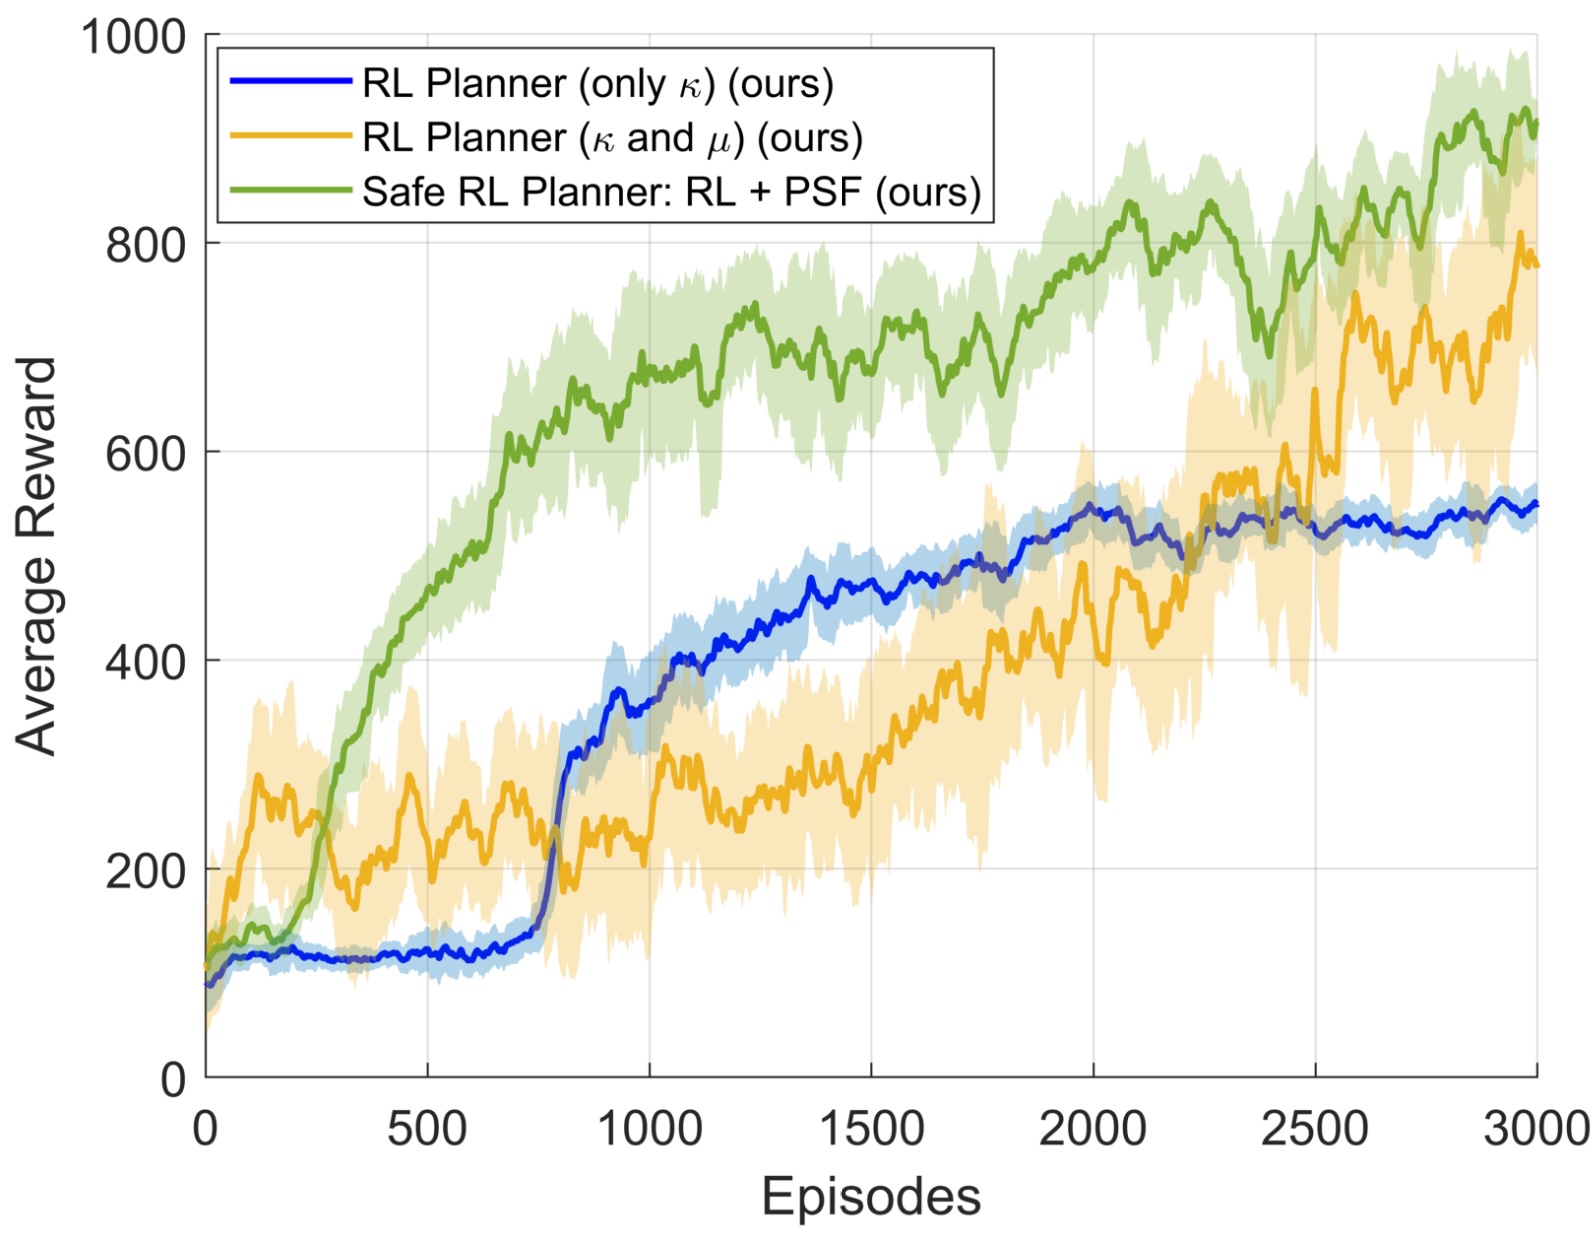
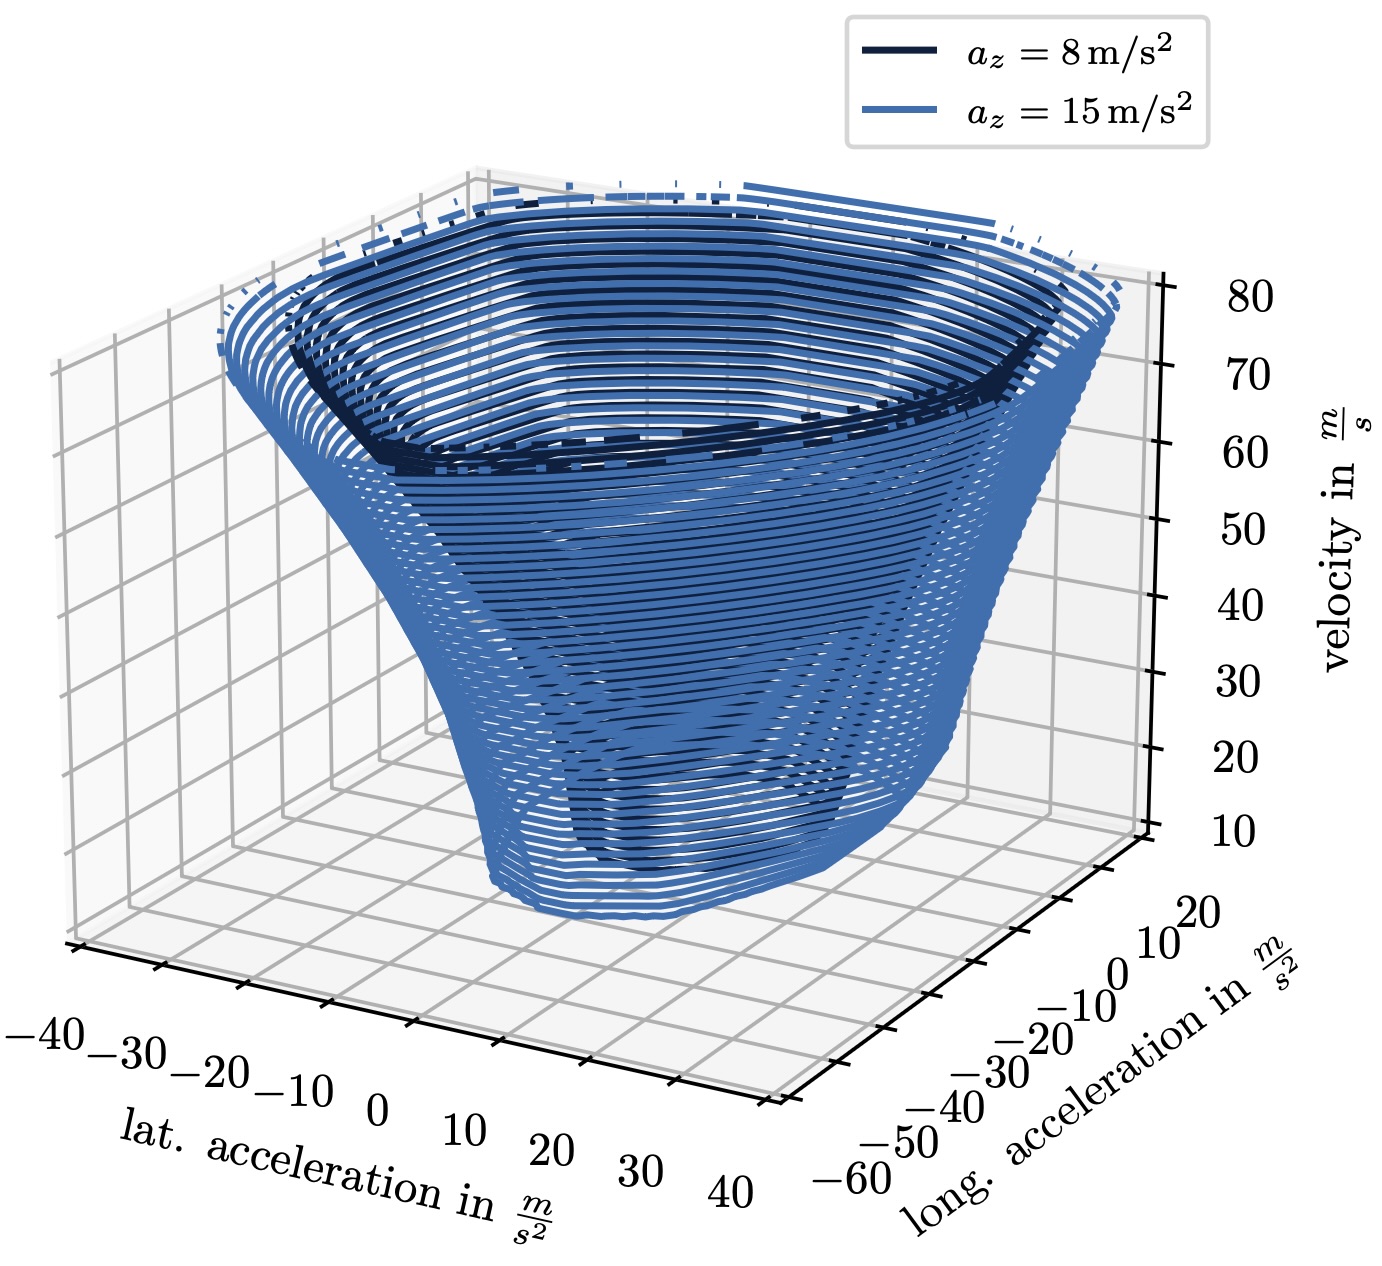
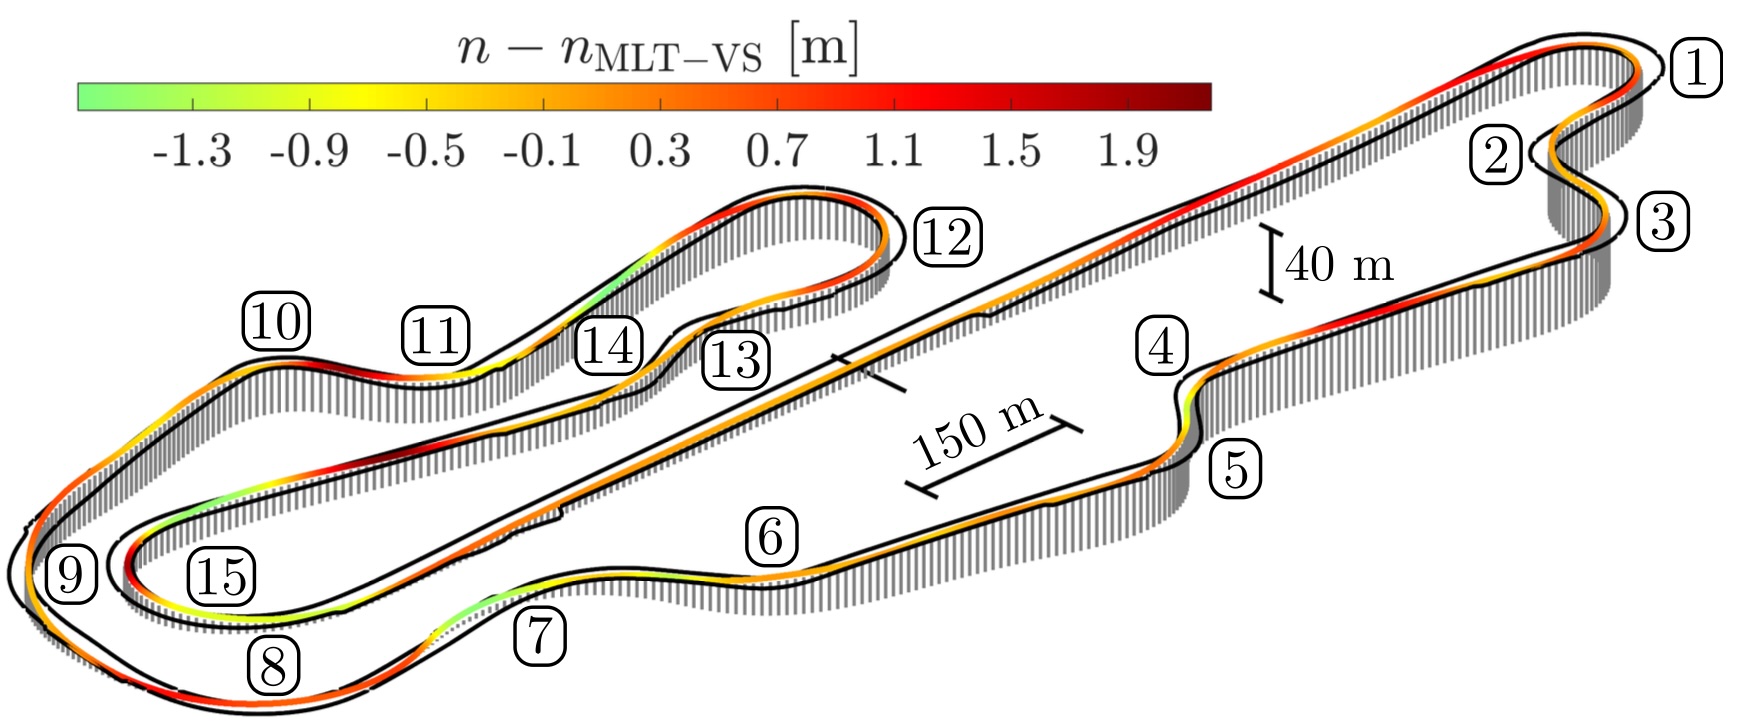
2024
-
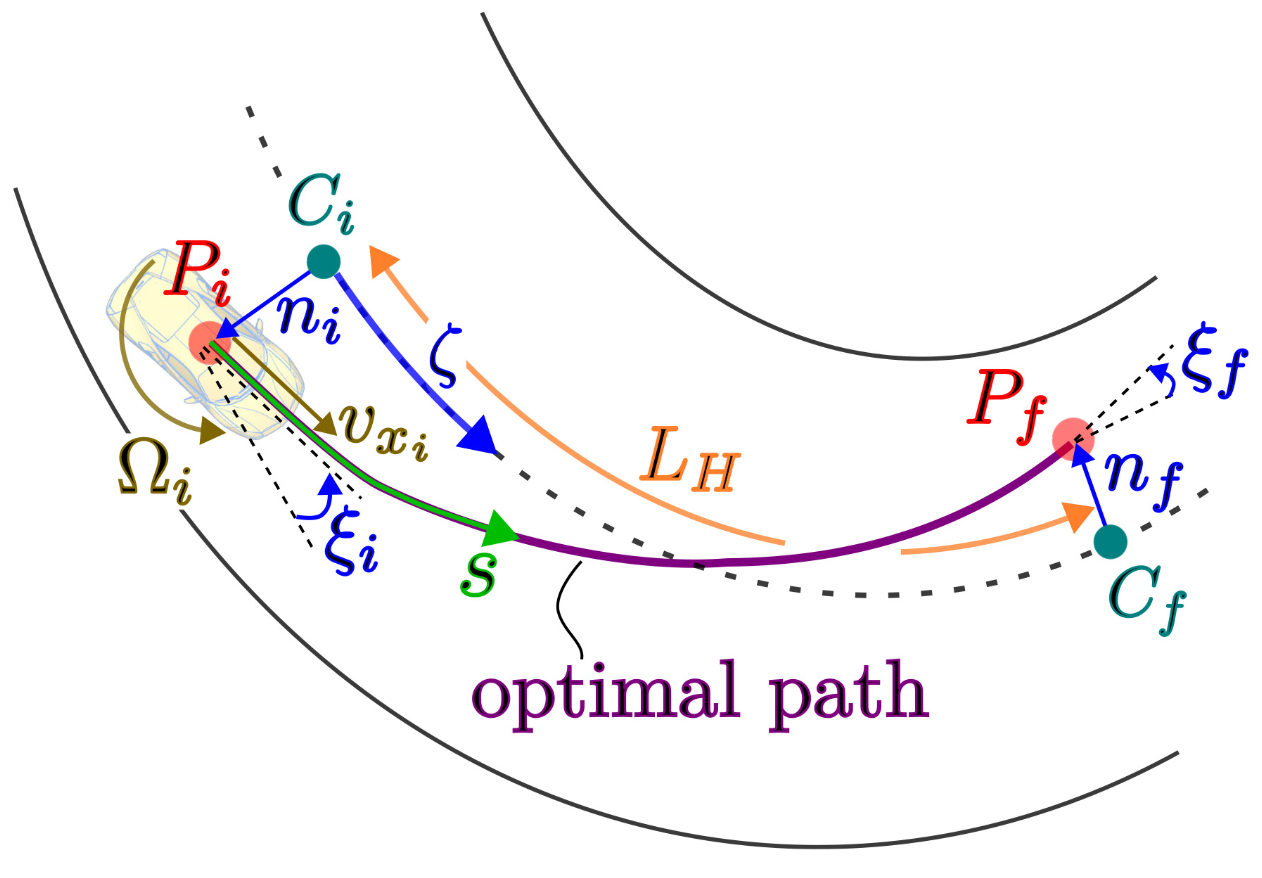 Neural Motion Primitives for Online Time-Optimal Vehicle Trajectory PlanningIn AUTOMATICA.IT 2024, 2024
-
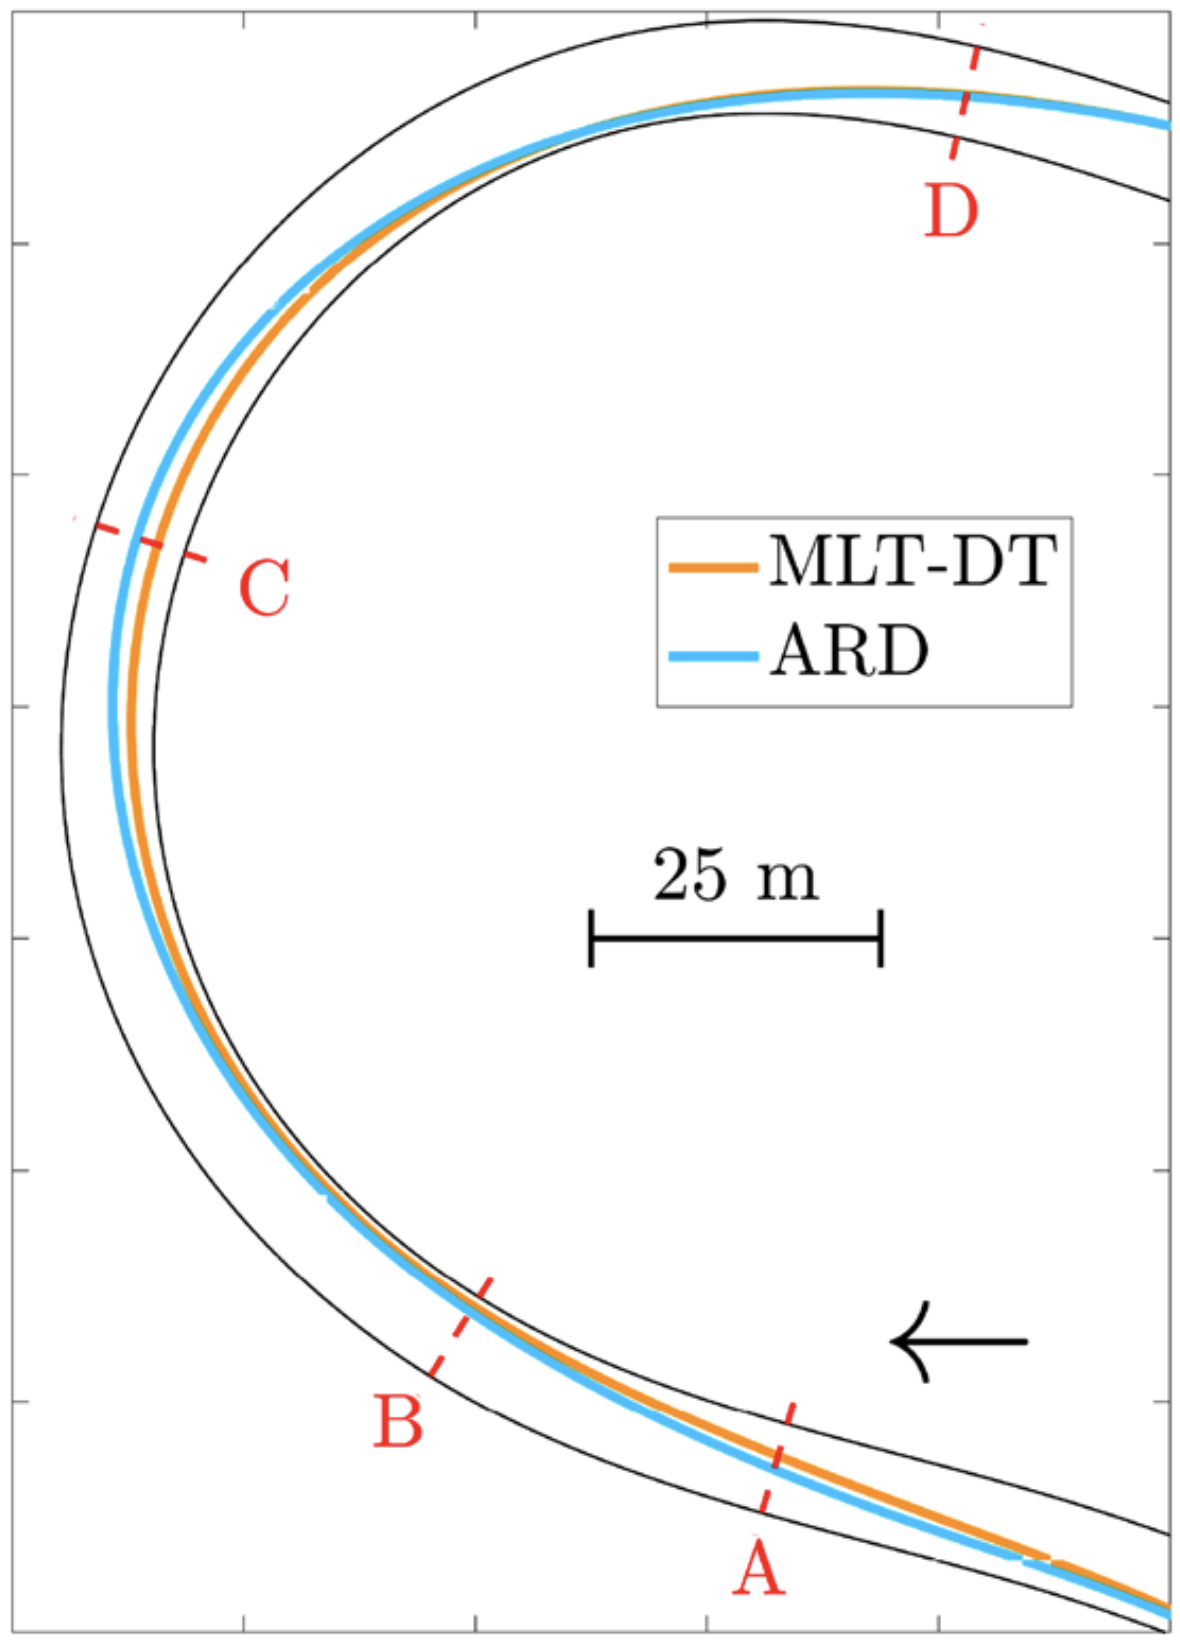 Artificial Racing Coach: Teaching Humans How to Maximize a Racing Vehicle’s Performance and Drive at Its LimitsIn AUTOMATICA.IT 2024, 2024
2023
-
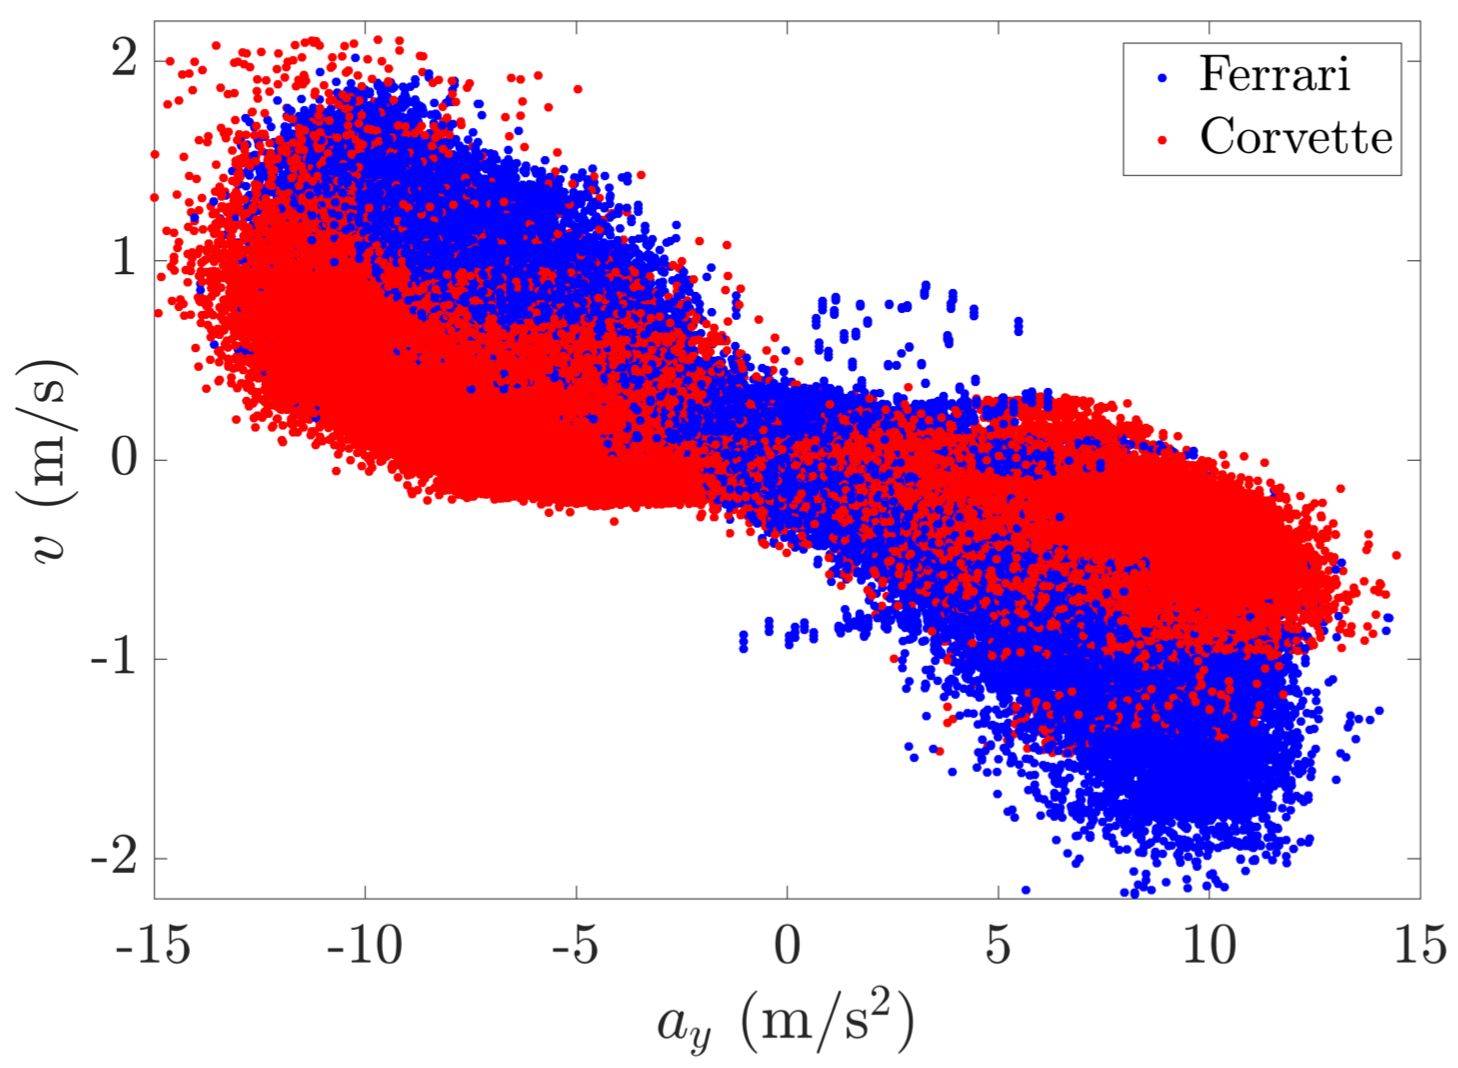 Device and method, based on neural networks, for estimating the lateral speed of vehicles2023Patent WO2023166536A1
-
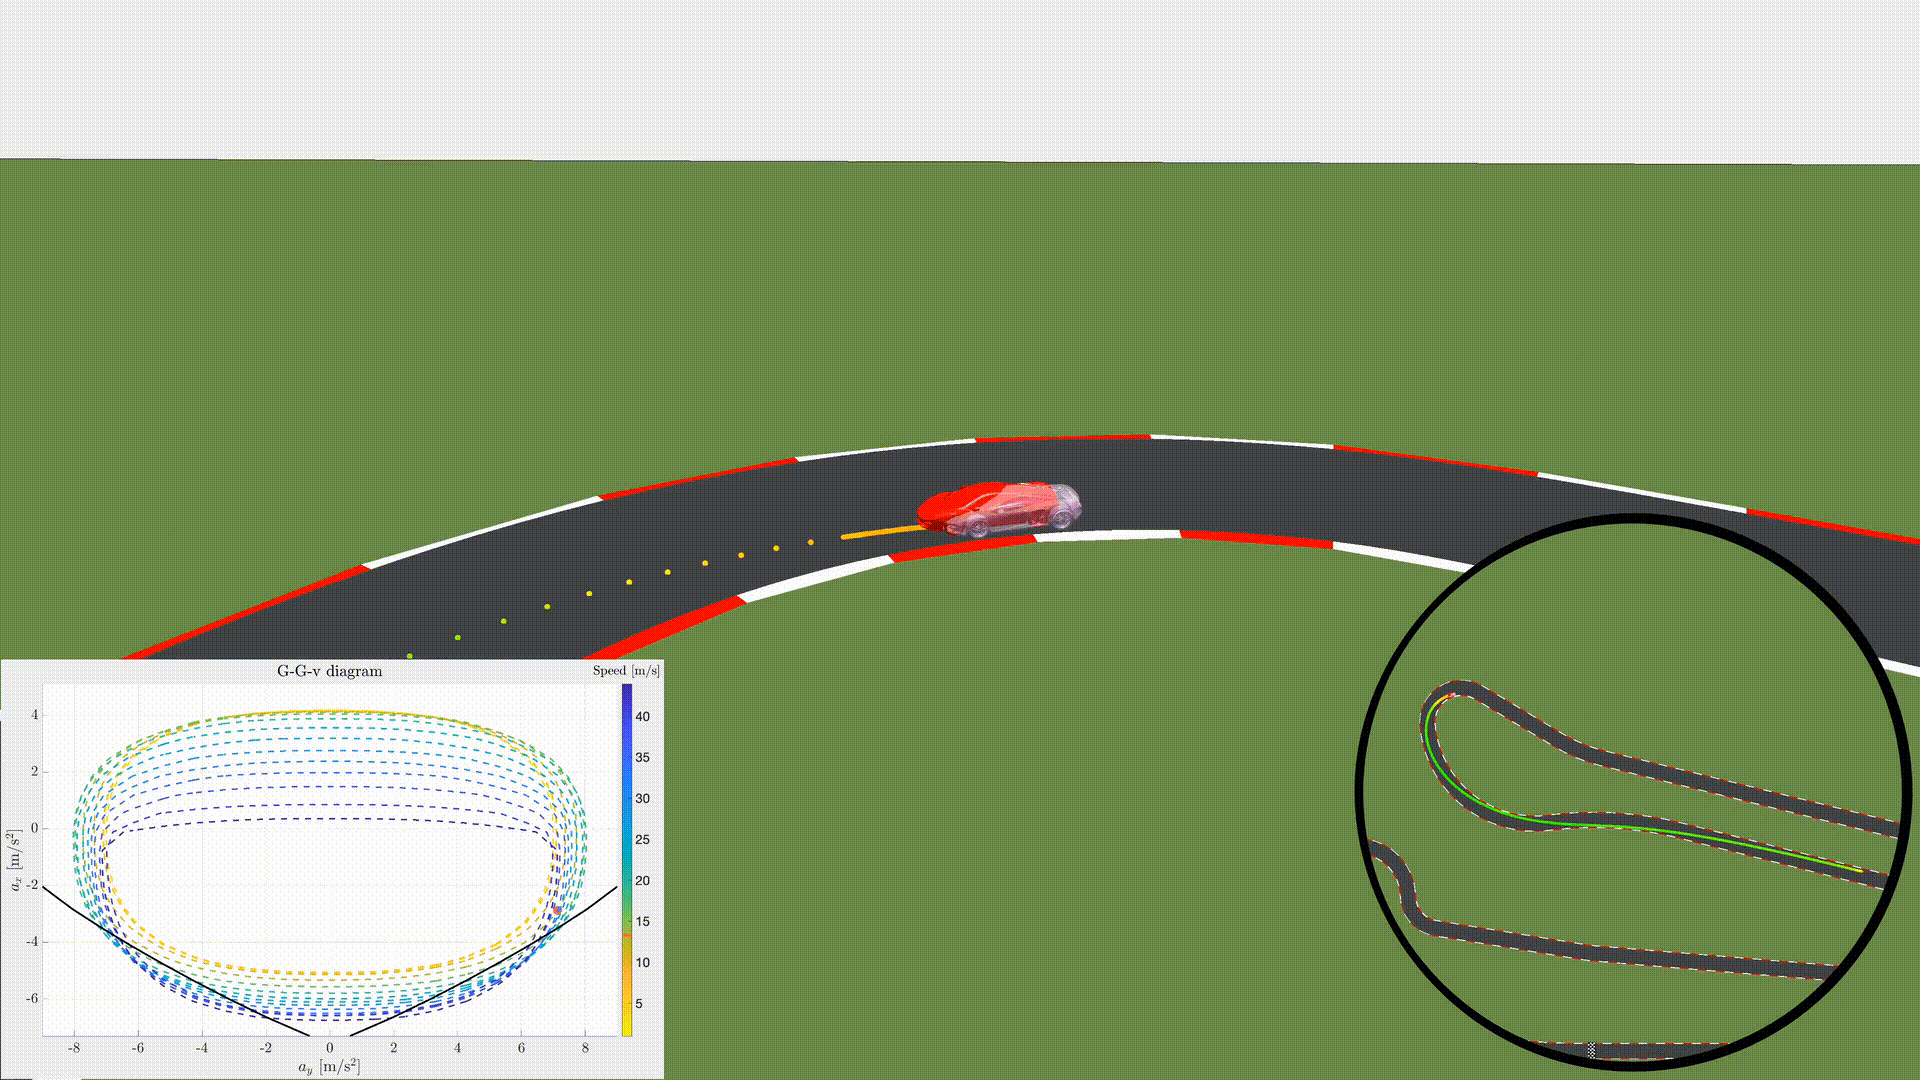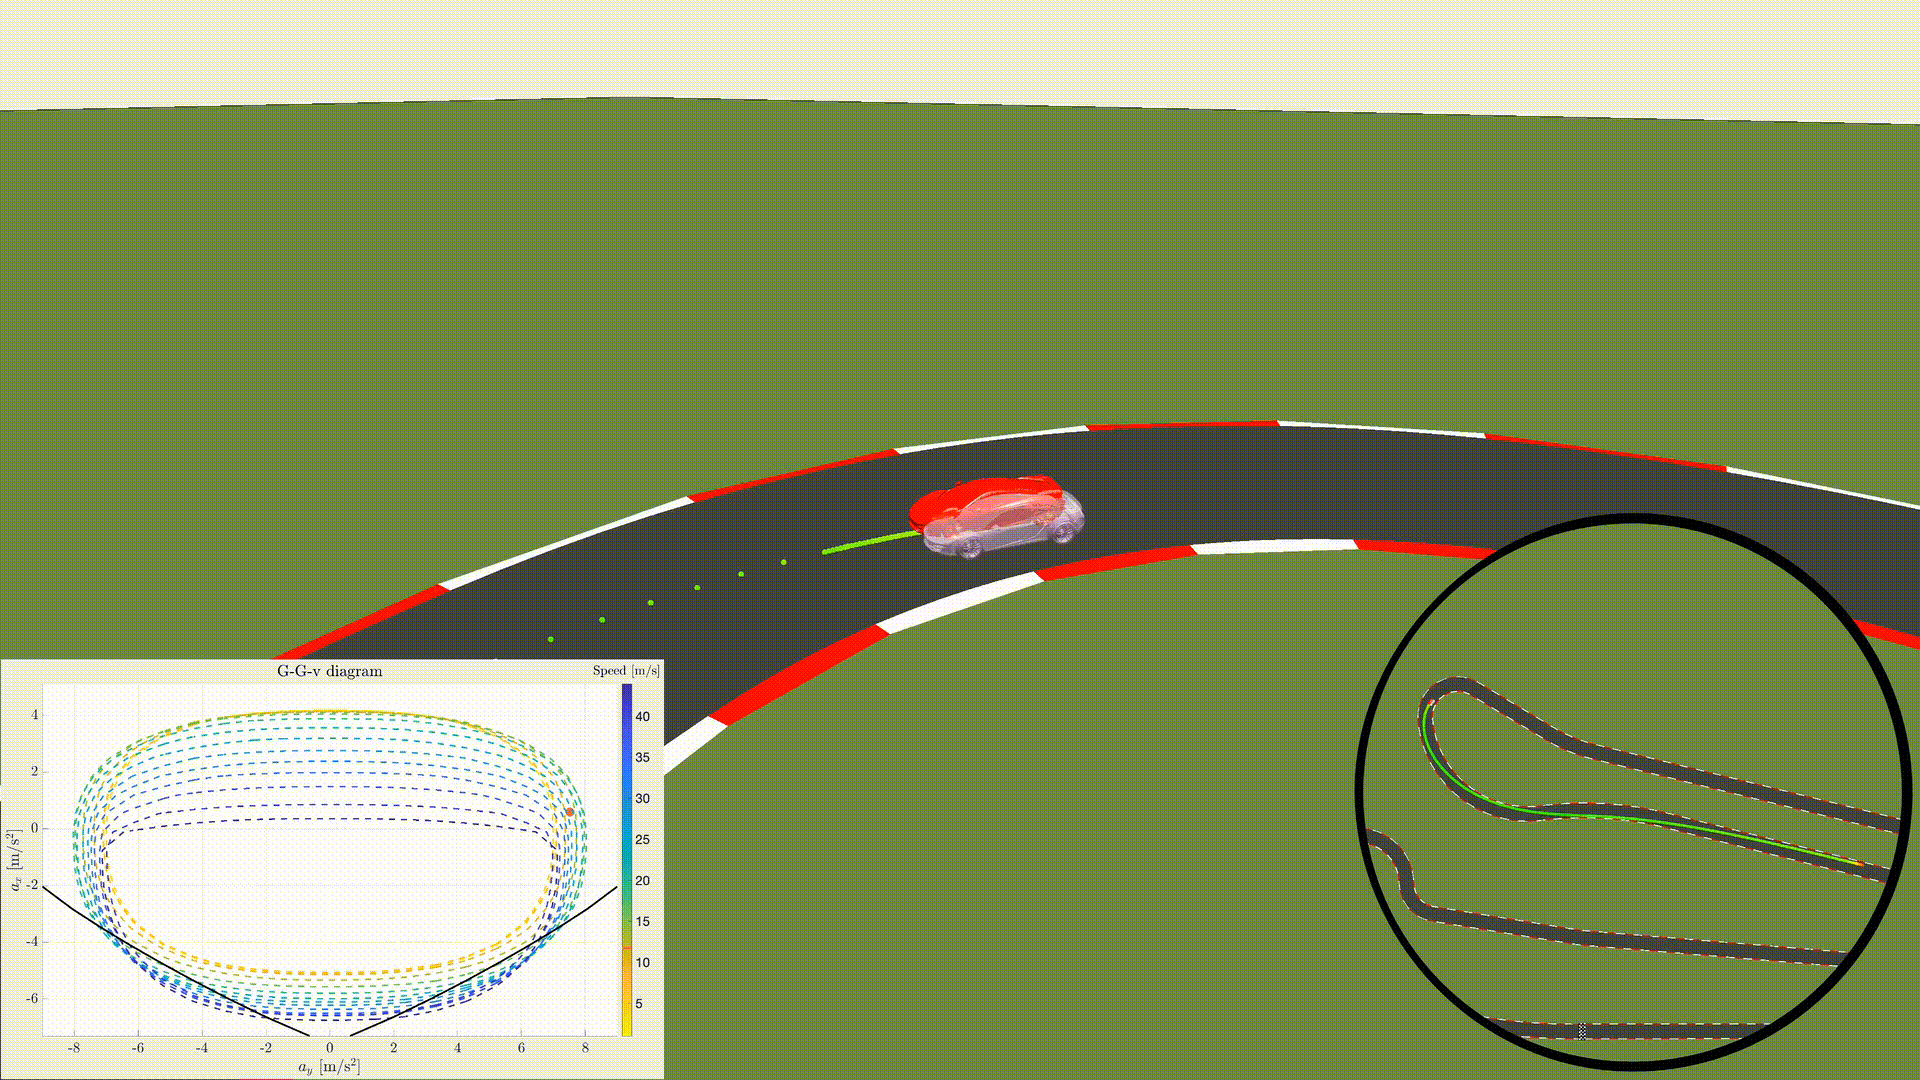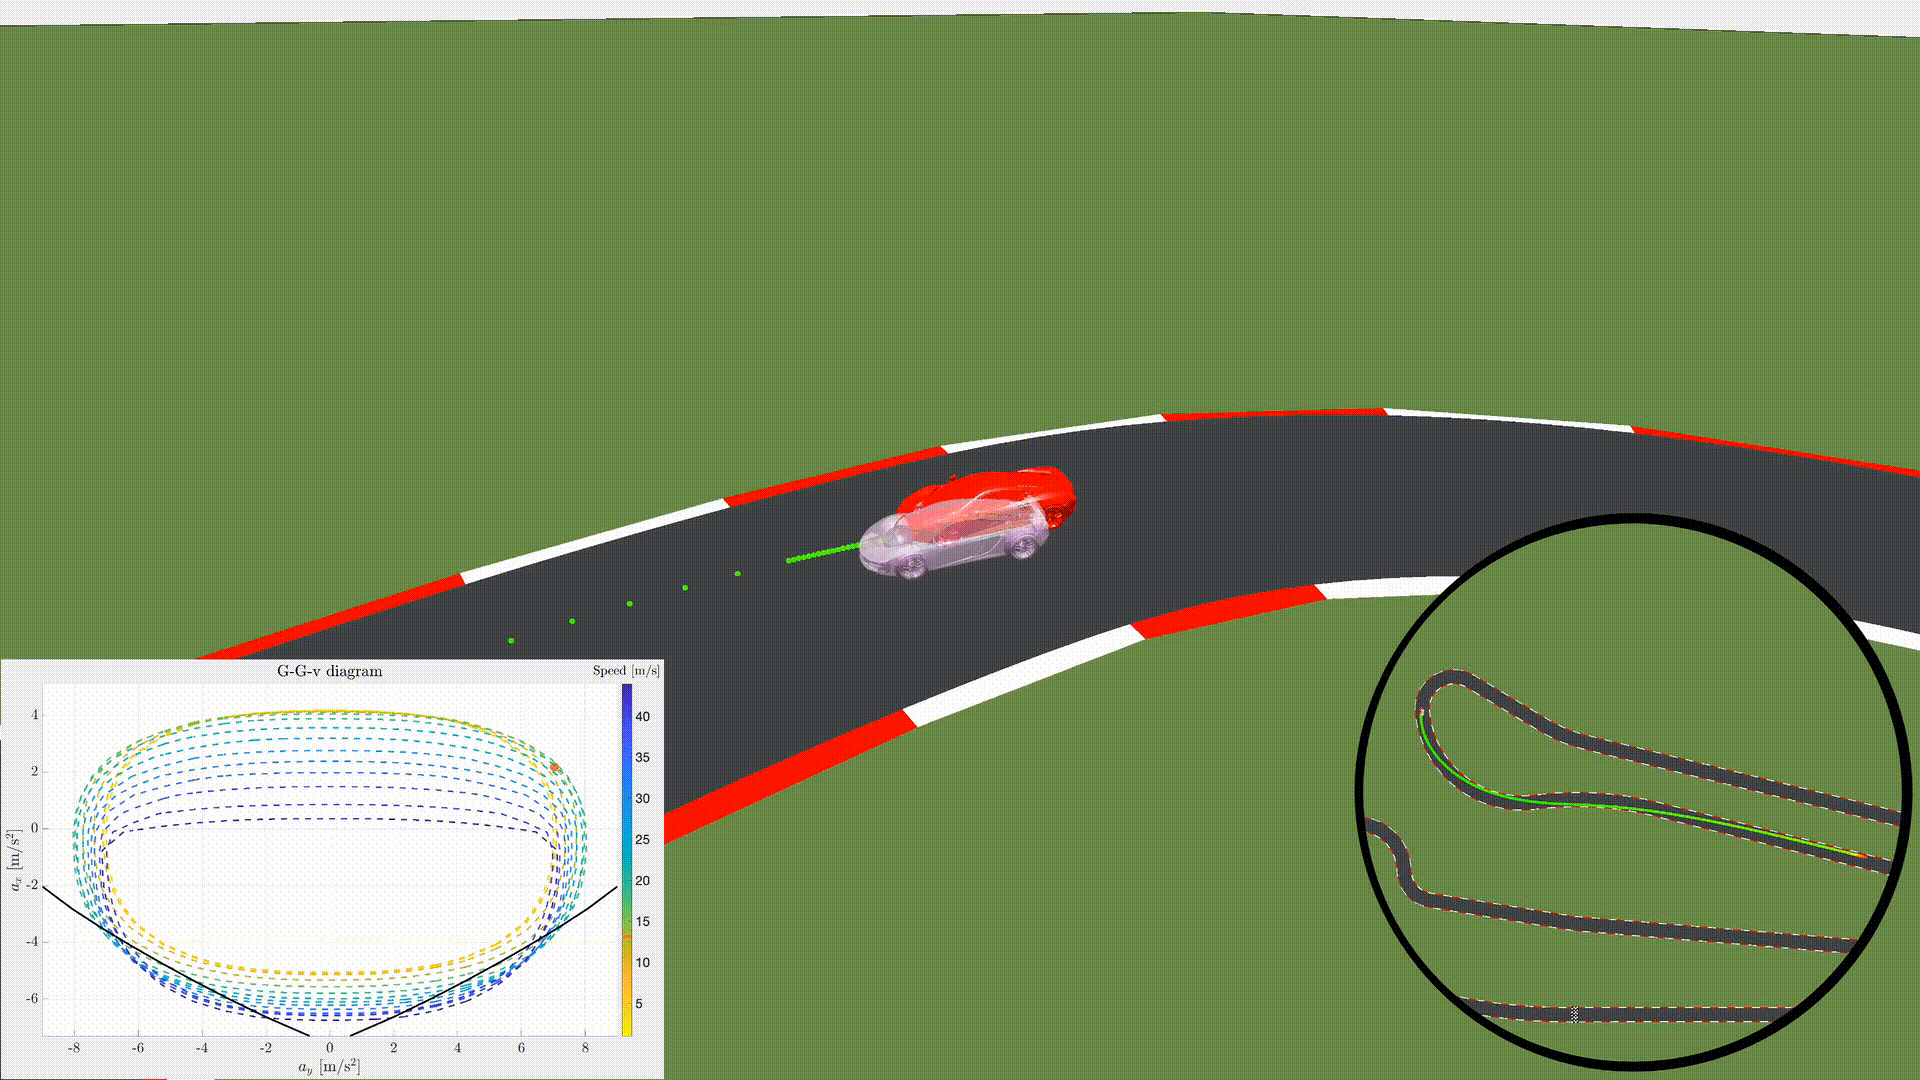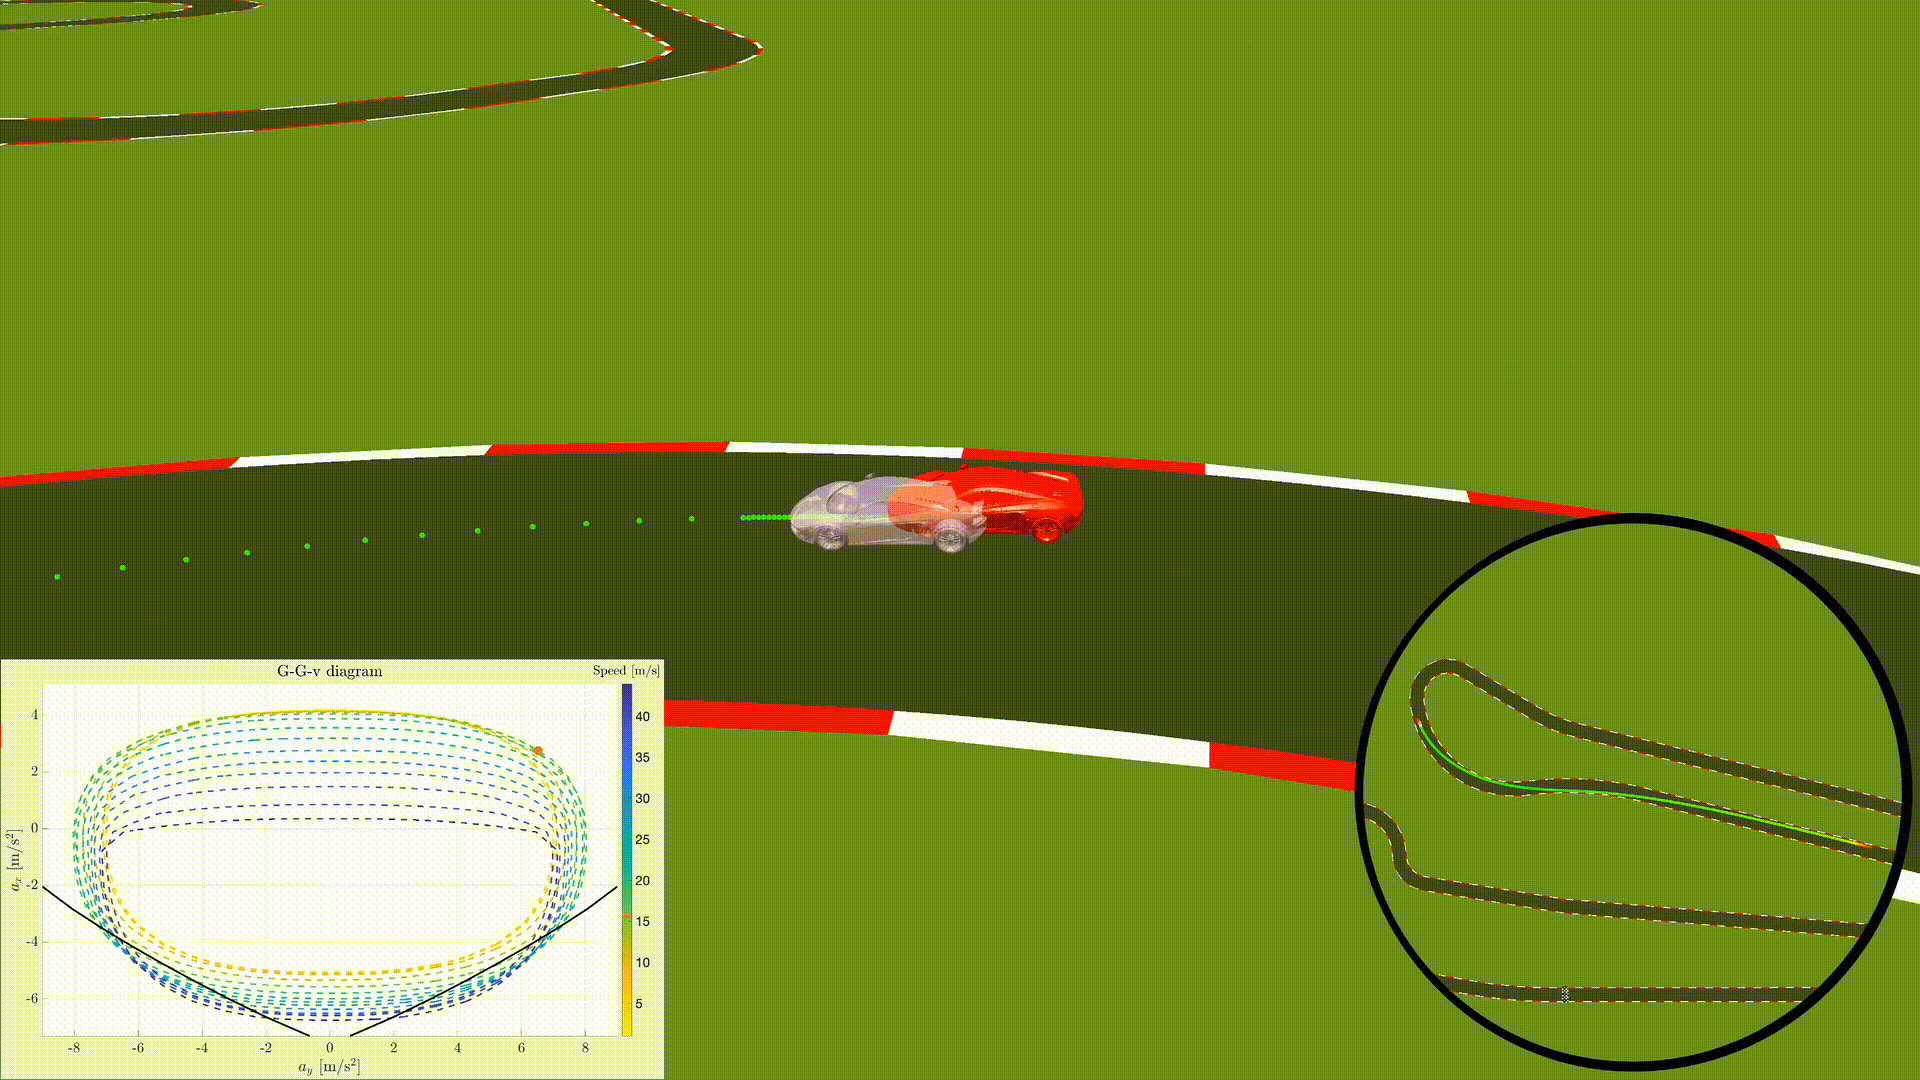 A Physics-Driven Framework for Online Minimum-Time Vehicle Motion Planning and ControlIn AUTOMATICA.IT 2023, 2023